


Step 8 — Grow autonomy
After stable manual flights, we grow missions. Better sensor fusion. Clear abort paths. Richer tasks stay for later. Backlog: later. Intro: what we build.
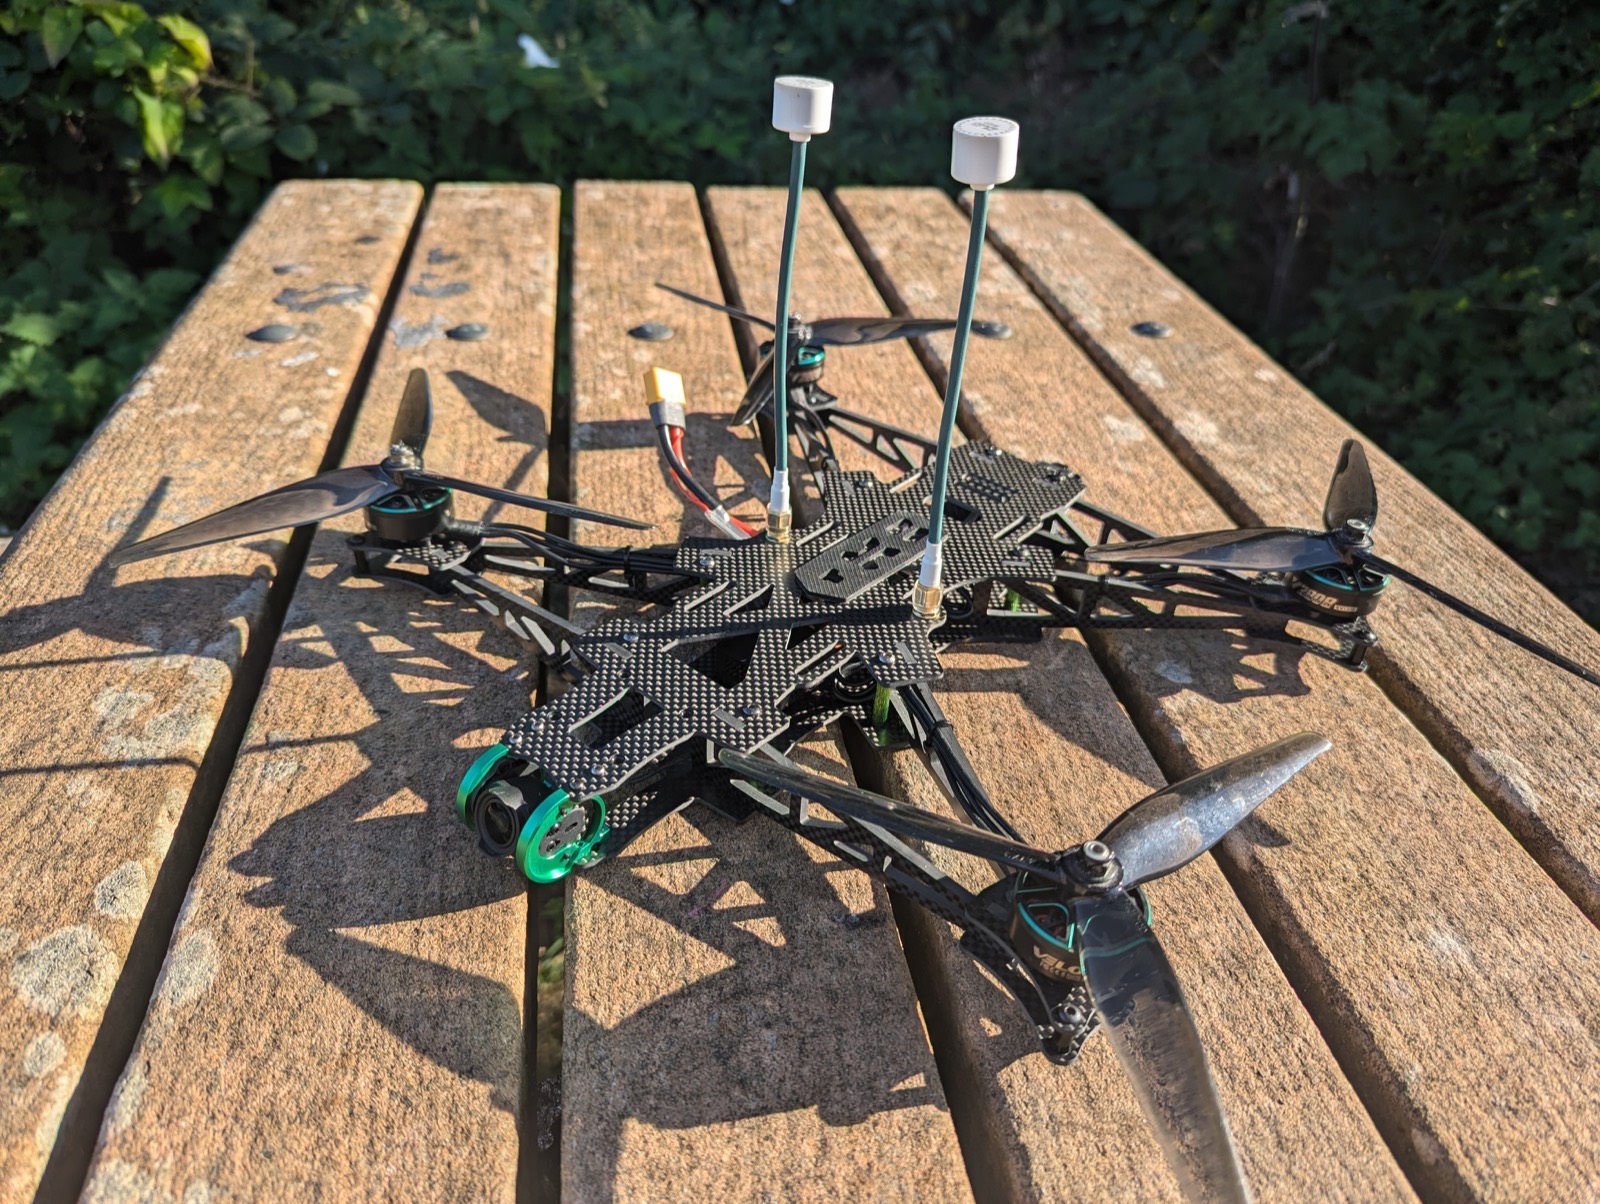
UL8 build — ready for missions
More images
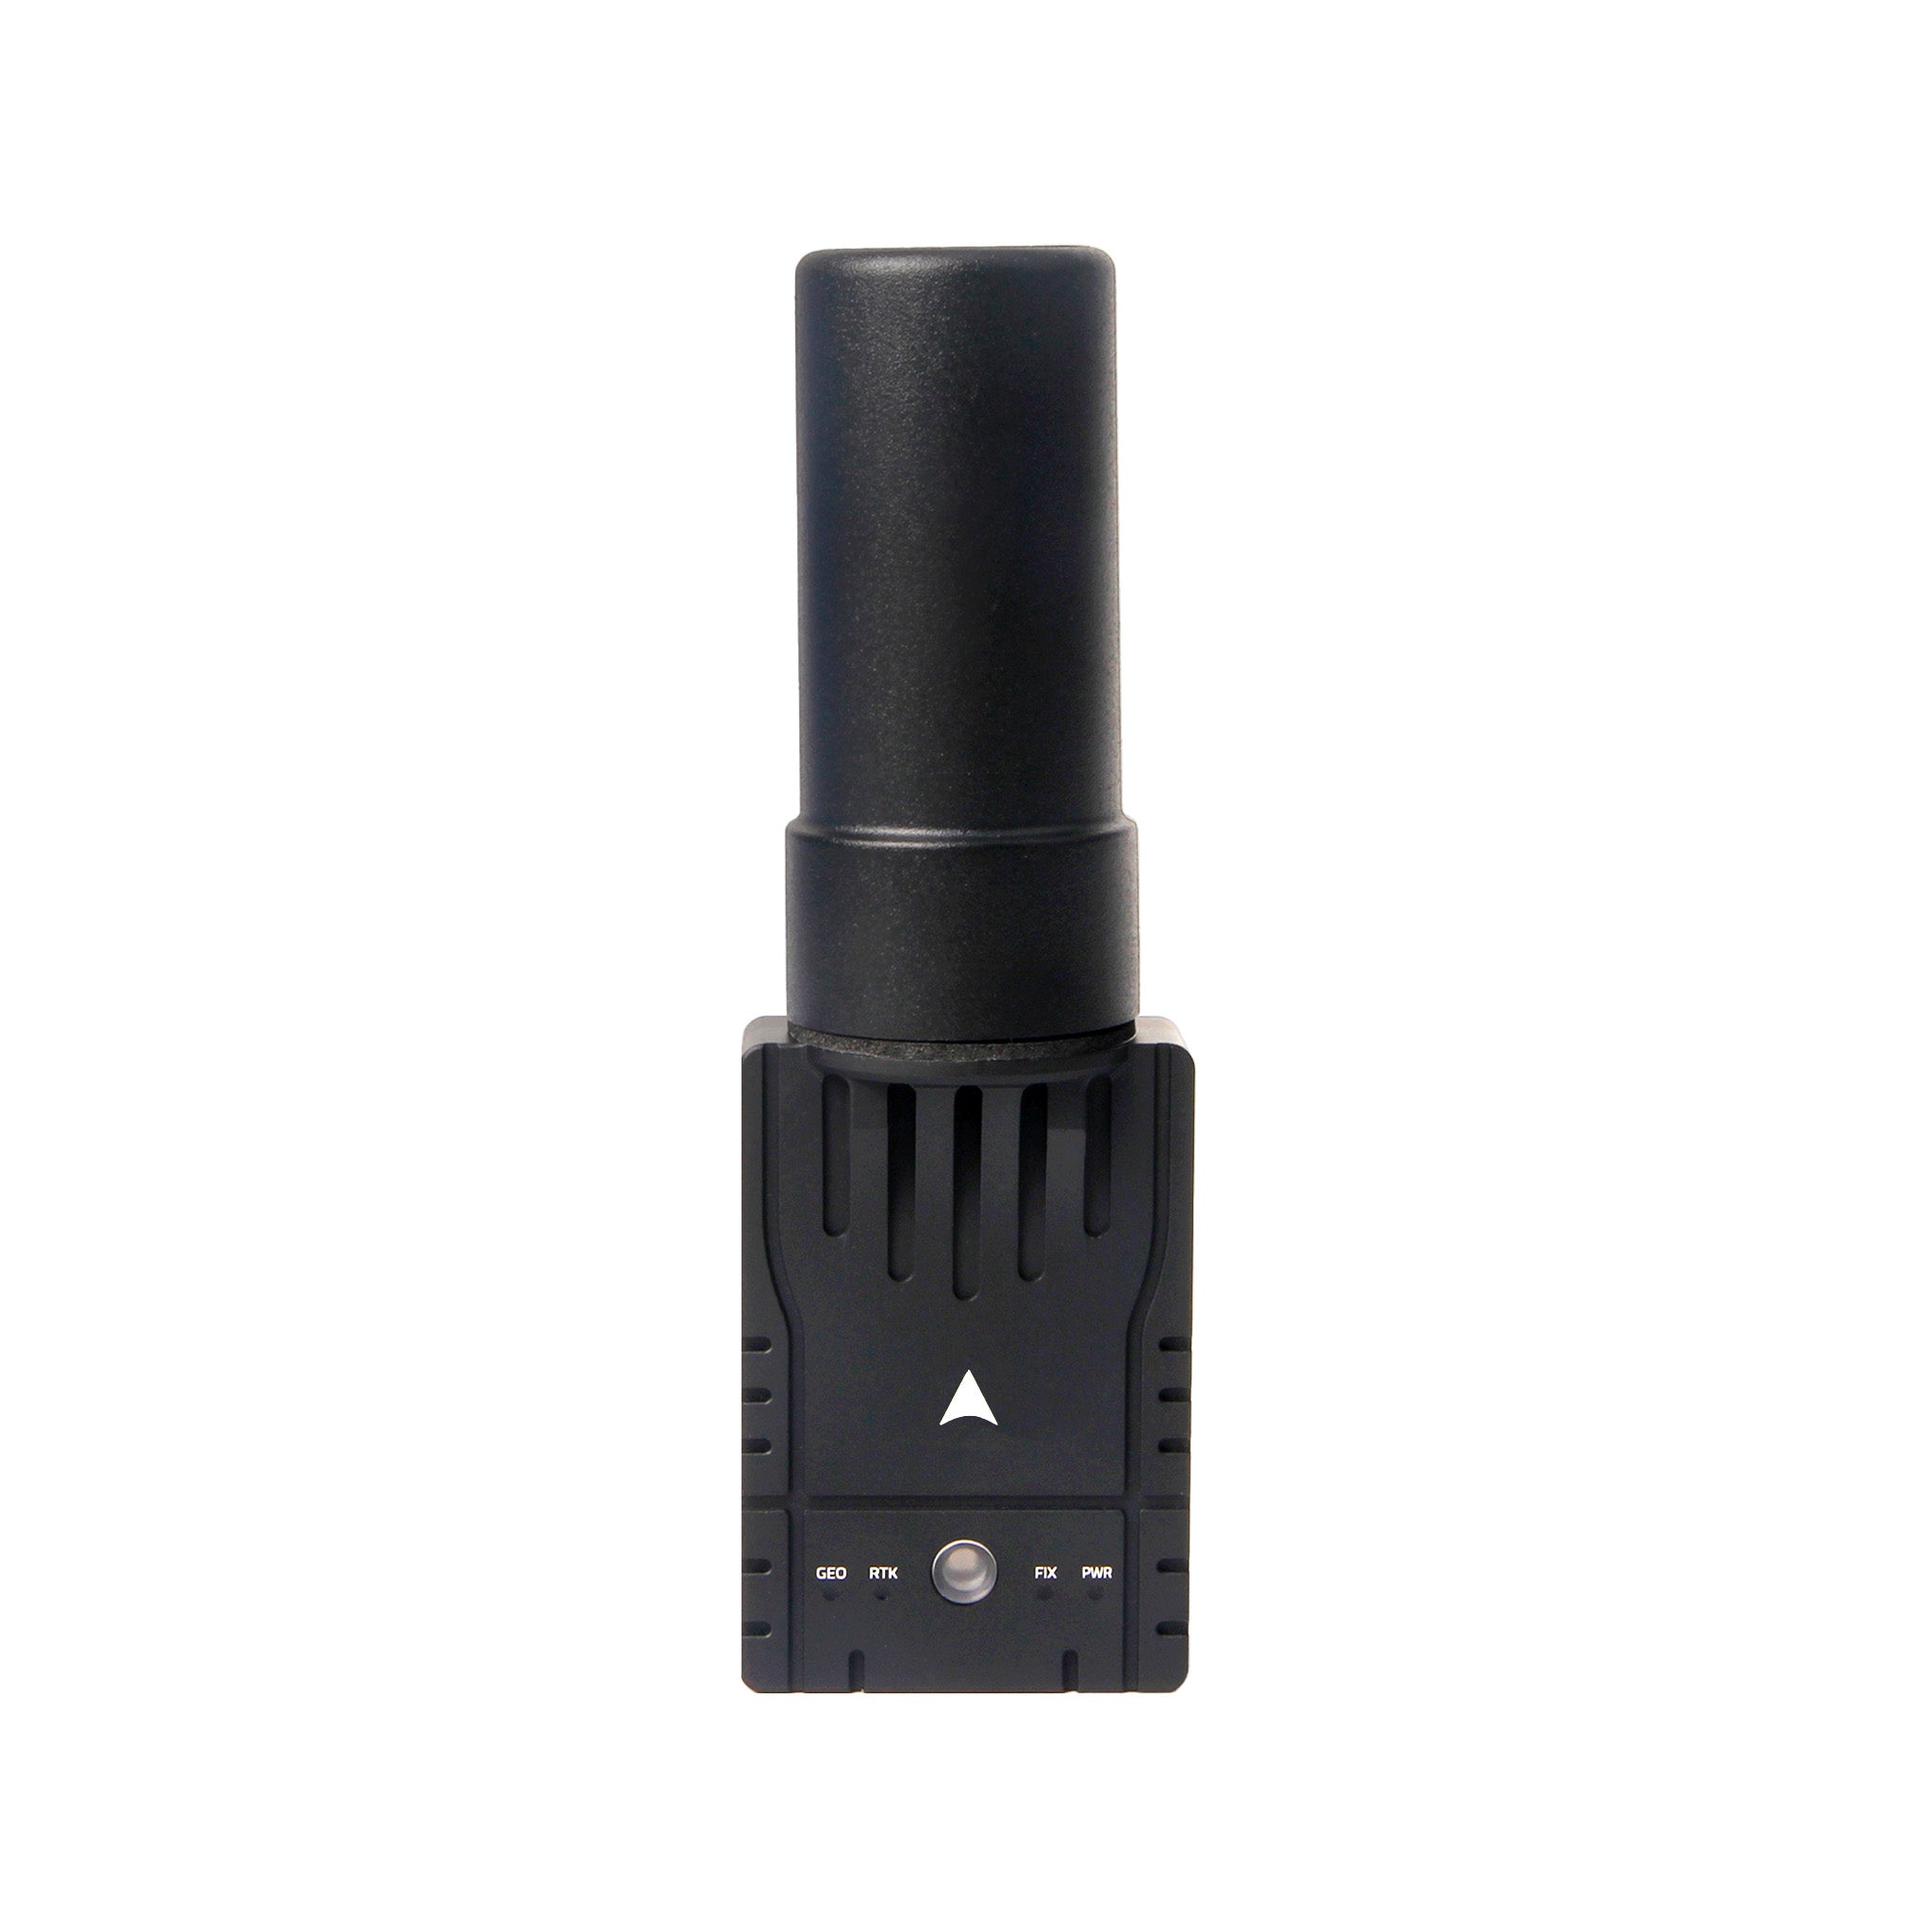
F9P for precise navigation
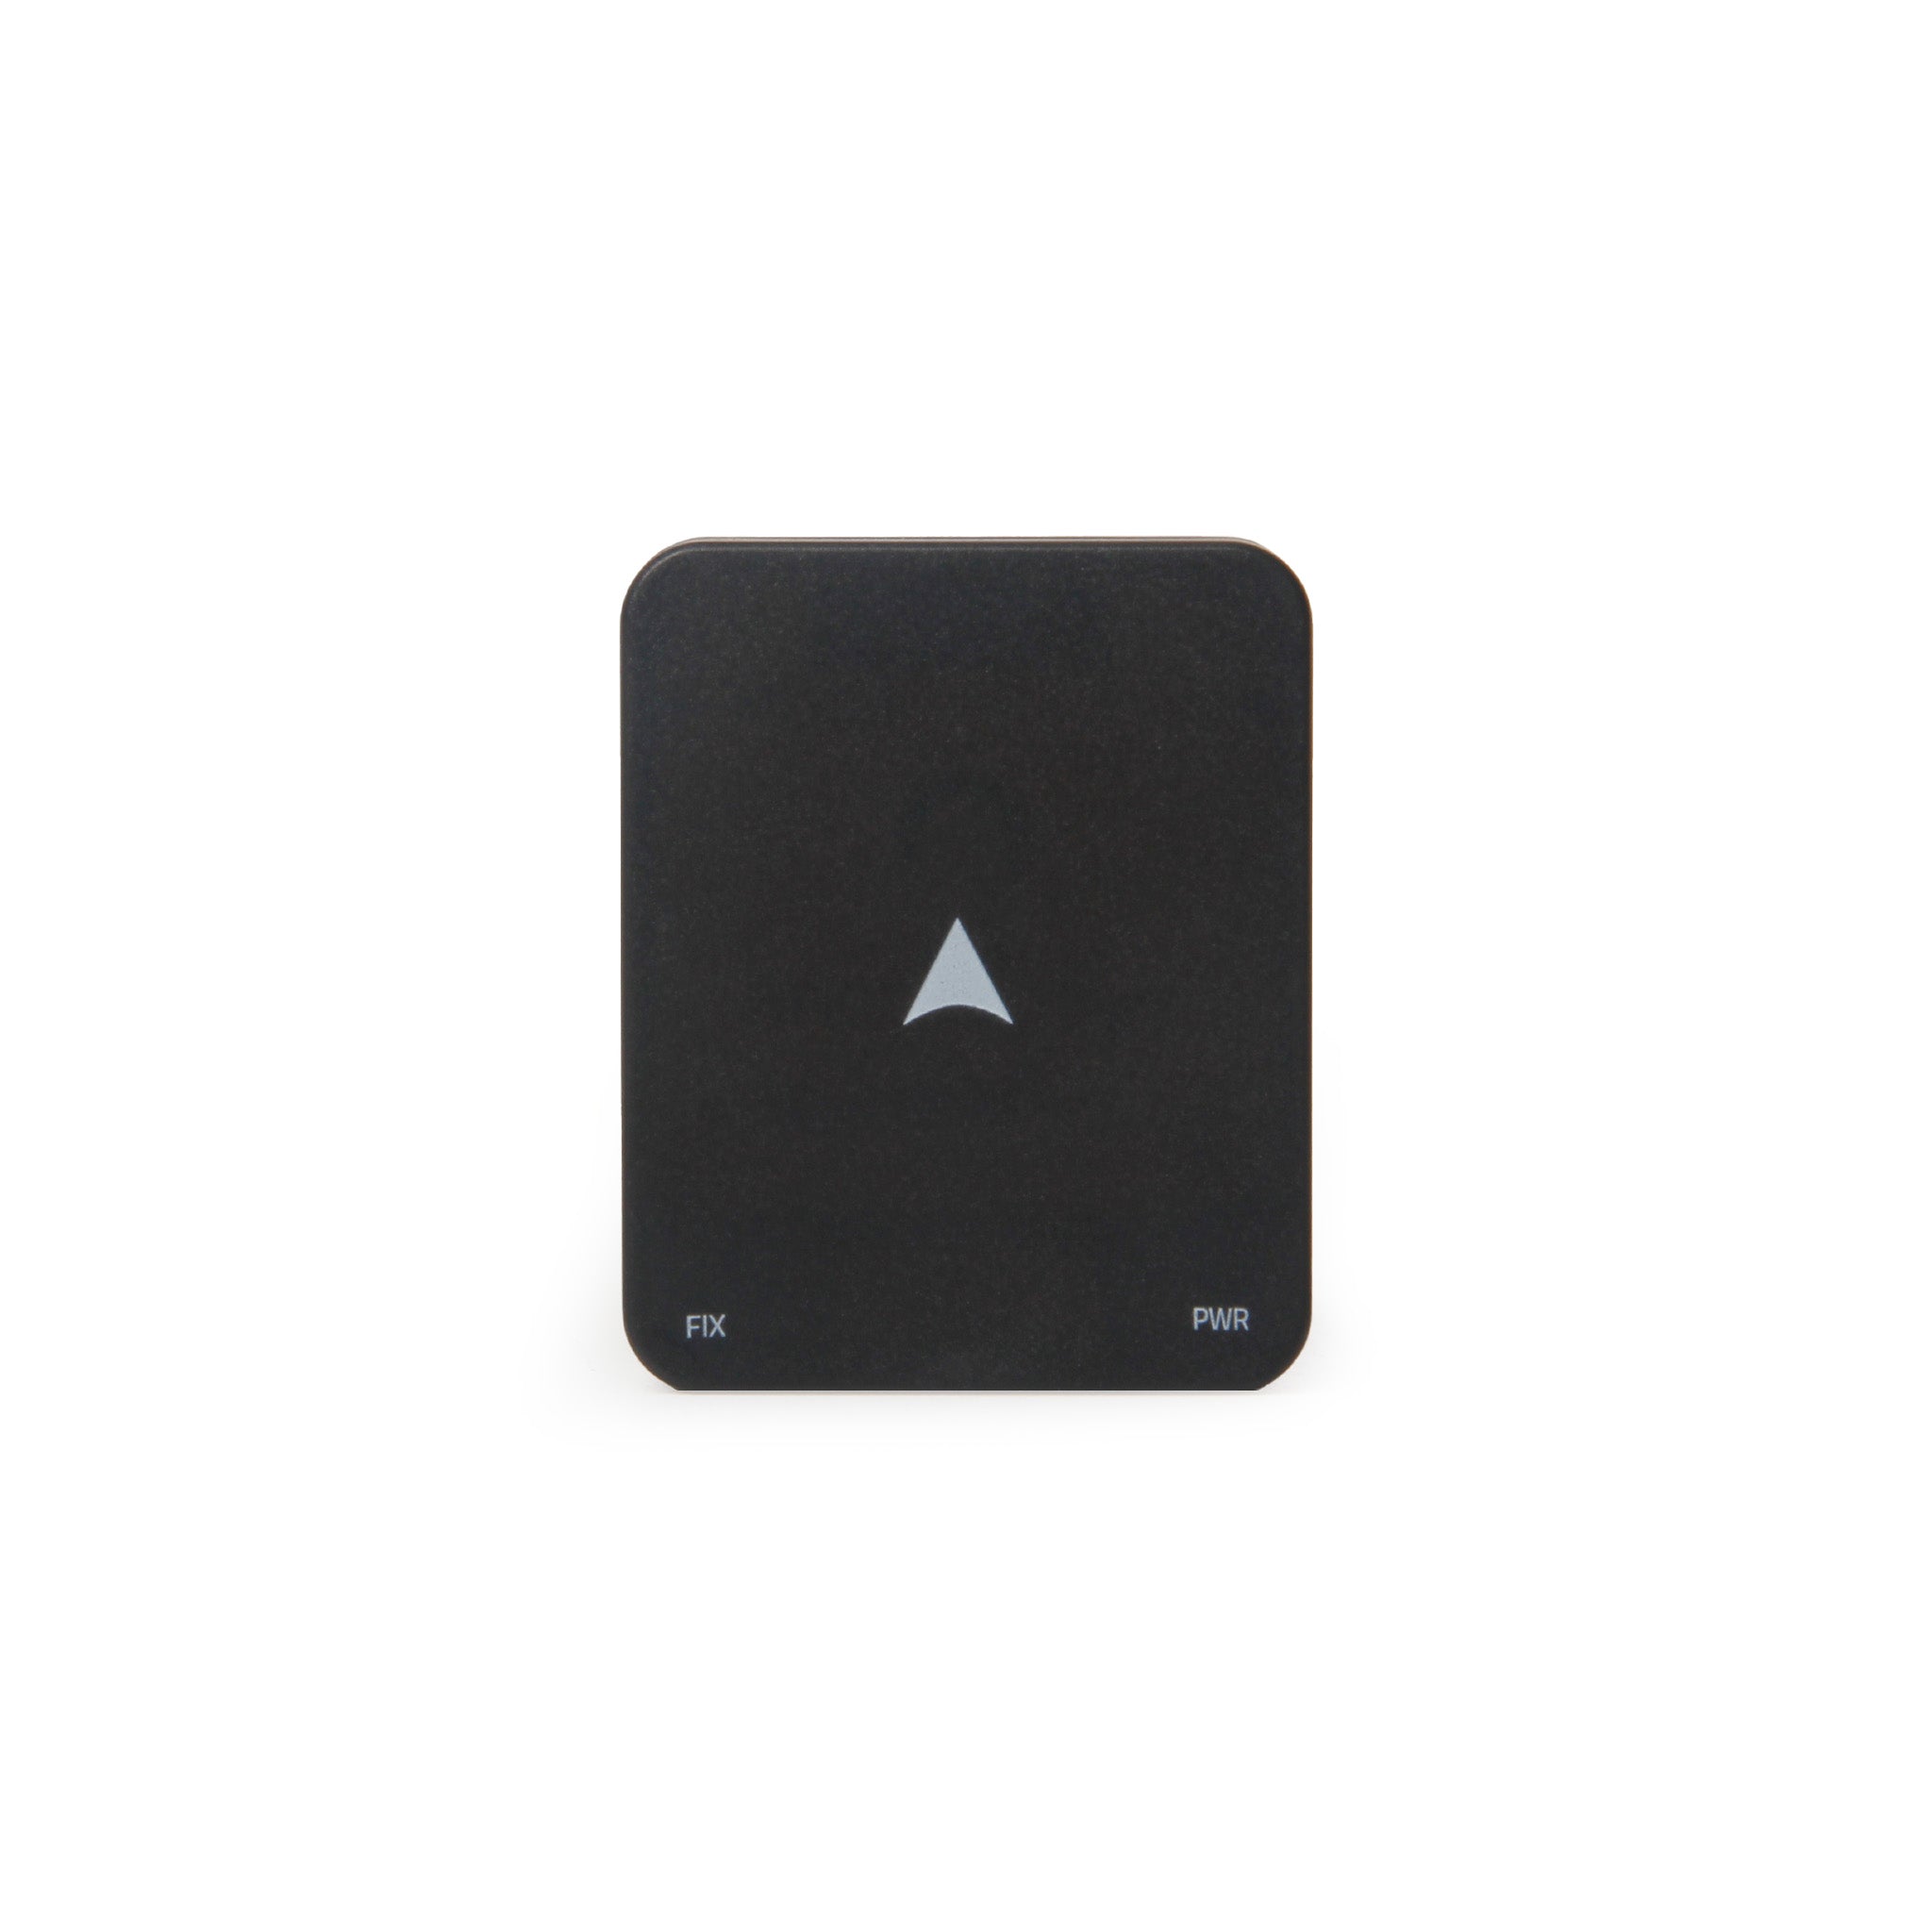
M9N GPS/compass
What we choose
Reproducible waypoints and RTL first. Then survey and triggers. Only once steps 1–7 are solid. Document every parameter change in the build log.
What we do
- Plan missions (waypoints, survey, RTL) with clear abort paths.
- Repeat the same task under varying GNSS/wind. Note failures and logs.
- Refine sensor fusion (GPS/RTK, flow, proximity) from real flights.
- Optionally add richer tasks (triggers, camera/survey) — only once 1–7 are solid.
- Document parameter changes in the per-part build log.
Manuals
- Mission Planner — Writing a mission
- ArduPilot — Auto mode
- ArduPilot — Mission Command List
- ArduPilot — Object avoidance (Auto path planning)
Video
How to Use Mission Planner — Waypoint Mission — YouTube
Path planning with Dijkstra (ArduPilot OA) — YouTube
Read next
- What we build
- ArduPilot settings — progress
- Step 7 — Config & first flights
- Later backlog
- Drone-build hub
Done when
Missions are reproducible enough for our use case. Improvements flow through logs + docs.
Choice log
| What | Missions + iteration |
| Why | Autonomy grows from evidence, not wishlists |
| Our pick | Waypoints/RTL first; richer tasks later; document everything |
Photos