


Step 7 — Config & first flights
Everything is mounted. Time for parameters, calibration, and a calm first flight (maiden). Go back to earlier steps if radio, GPS, or power still wobble. Firmware: firmware page.
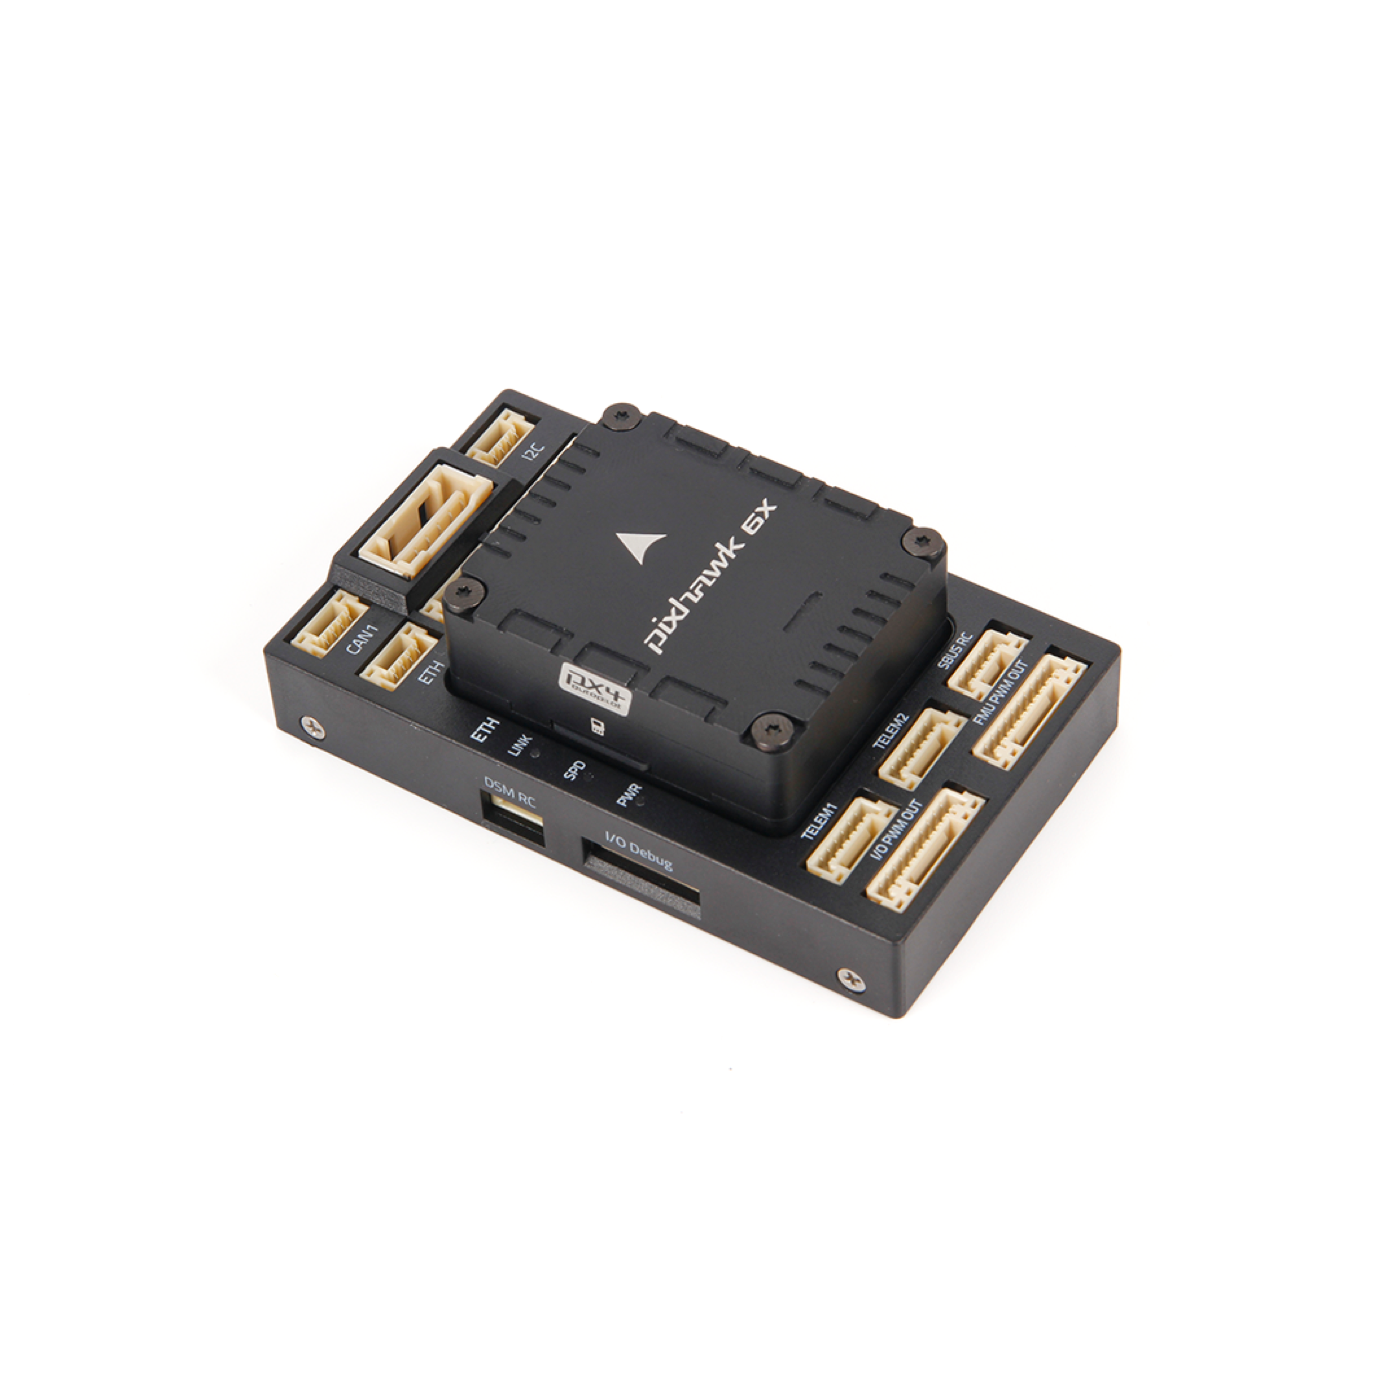
Pixhawk 6X Mini — ready for setup
More images
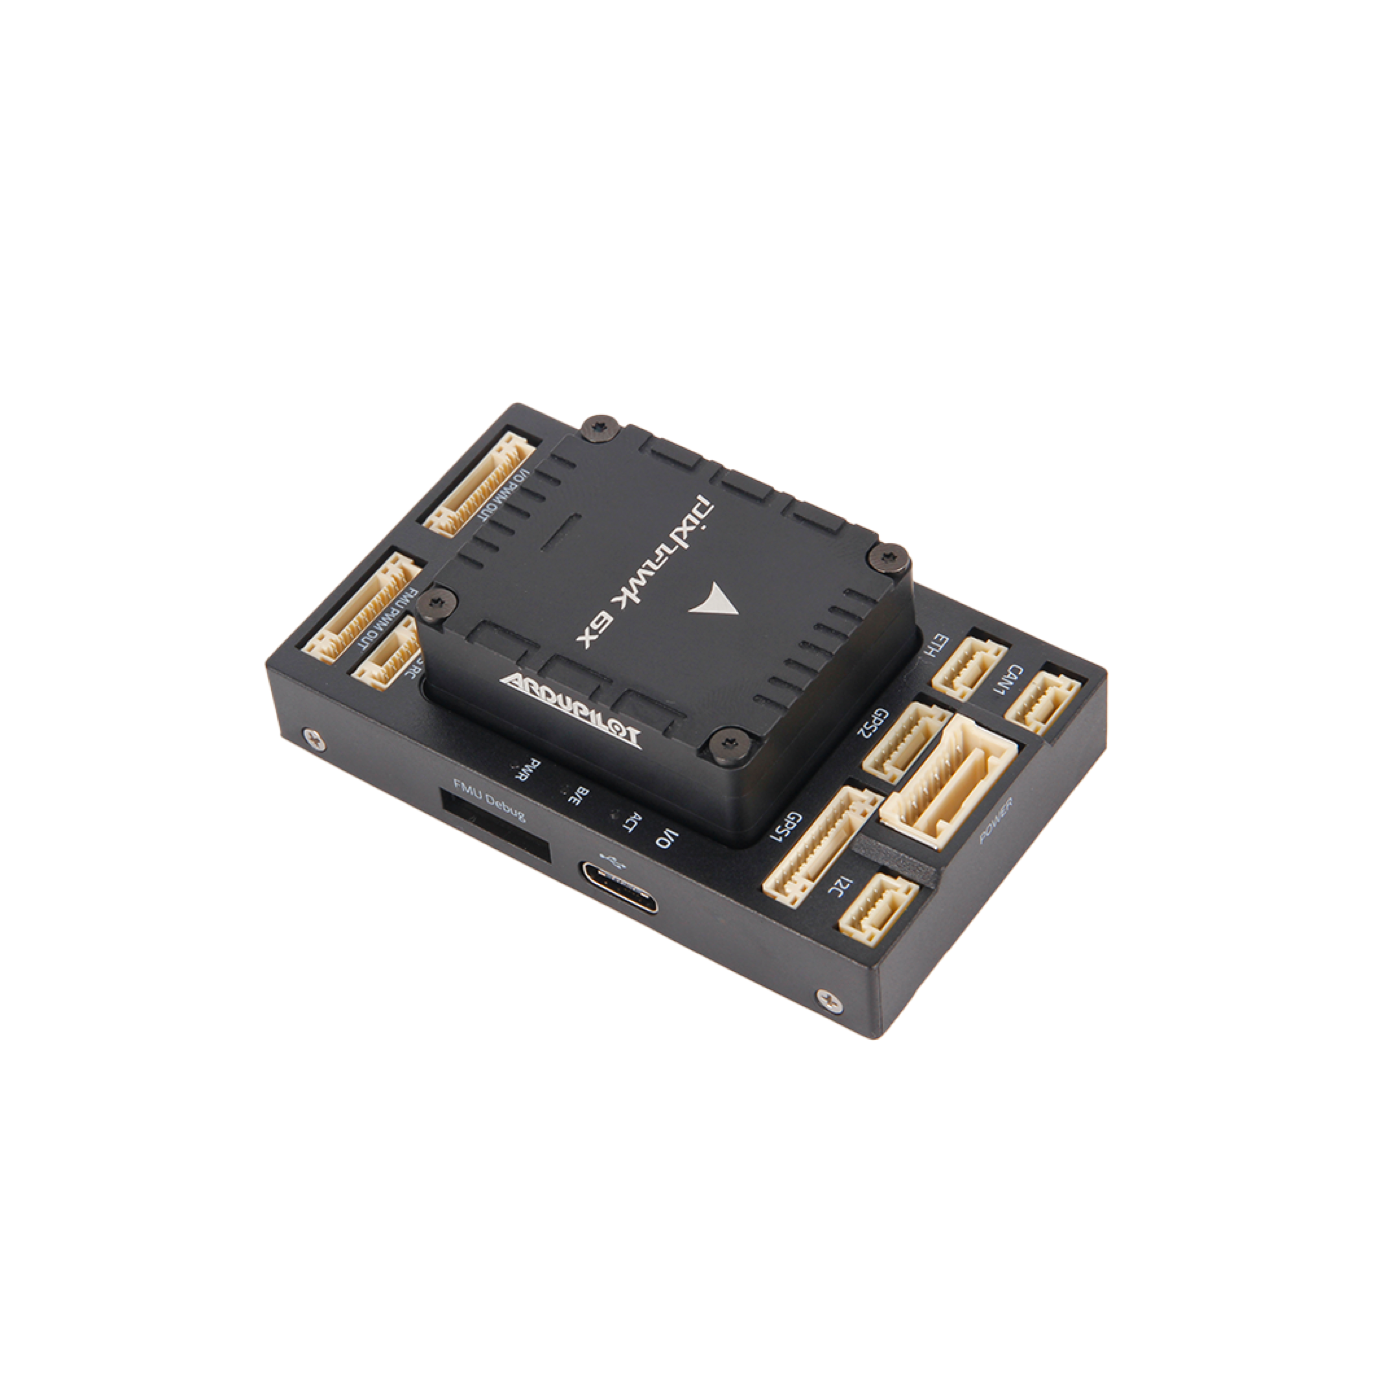
Stack / module
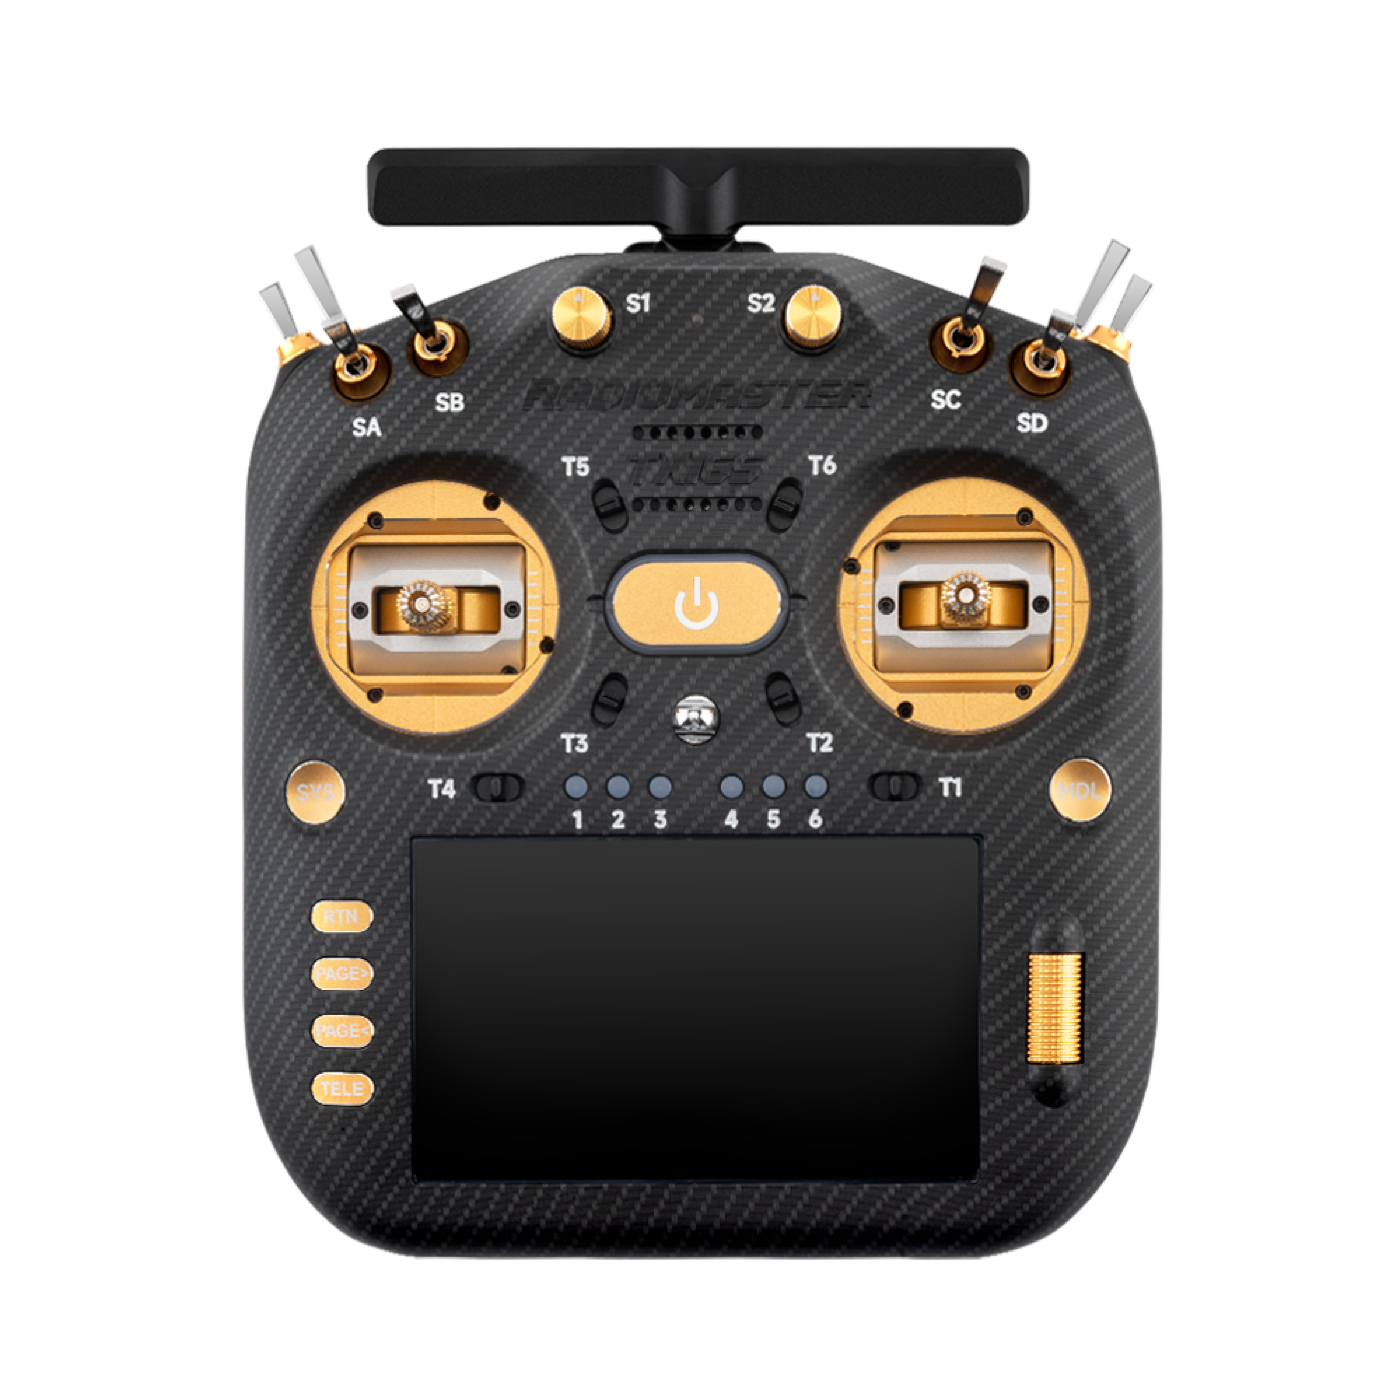
TX16S for radio calibration
What we choose
Manual and stable modes first. Auto and missions only after that. Failsafe, geofence, arming checks, and logging on. PID only in small steps.
What we do
- Lock frame type, motor order, ESC protocol (DShot), and battery parameters.
- Accel/compass/radio/ESC calibration (without props where required).
- Enable failsafe, geofence, arming checks, and logging.
- First flights: Stabilize → AltHold → Loiter/PosHold. Only then Auto.
- Review logs. Change PID/filters only in small steps.
Manuals
- ArduPilot — Mandatory hardware configuration
- Mission Planner — Initial setup
- ArduPilot — Flight modes (Copter)
- ArduPilot — Tips for new pilots
- Complete hardware & tuning intro (video series)
Video
Complete ArduPilot Tuning Guide — Part 1 Hardware and Setup — YouTube
First flight — Stabilize, AltHold, PosHold and Autotune — YouTube
Read next
- Pixhawk 6X Mini
- ArduPilot settings — progress
- ArduPilot + ELRS setup
- Step 4 — Radio & telemetry
- Step 8 — Grow autonomy
Done when
Manual/stable modes are reliable. Auto/waypoints have been tested in an open field.
Choice log
| What | Calibration, failsafe, first flight |
| Why | Until we can fly safely |
| Our pick | Stabilize → AltHold → Loiter first; Auto later; small PID steps |
Photos