


Step 5 — Low-speed sensing
Indoors and near the ground, H-Flow (optical flow + distance) helps where GPS is weak. We validate that sensor now. Hard avoidance comes later. Go back to step 3 if CAN is not ready yet.
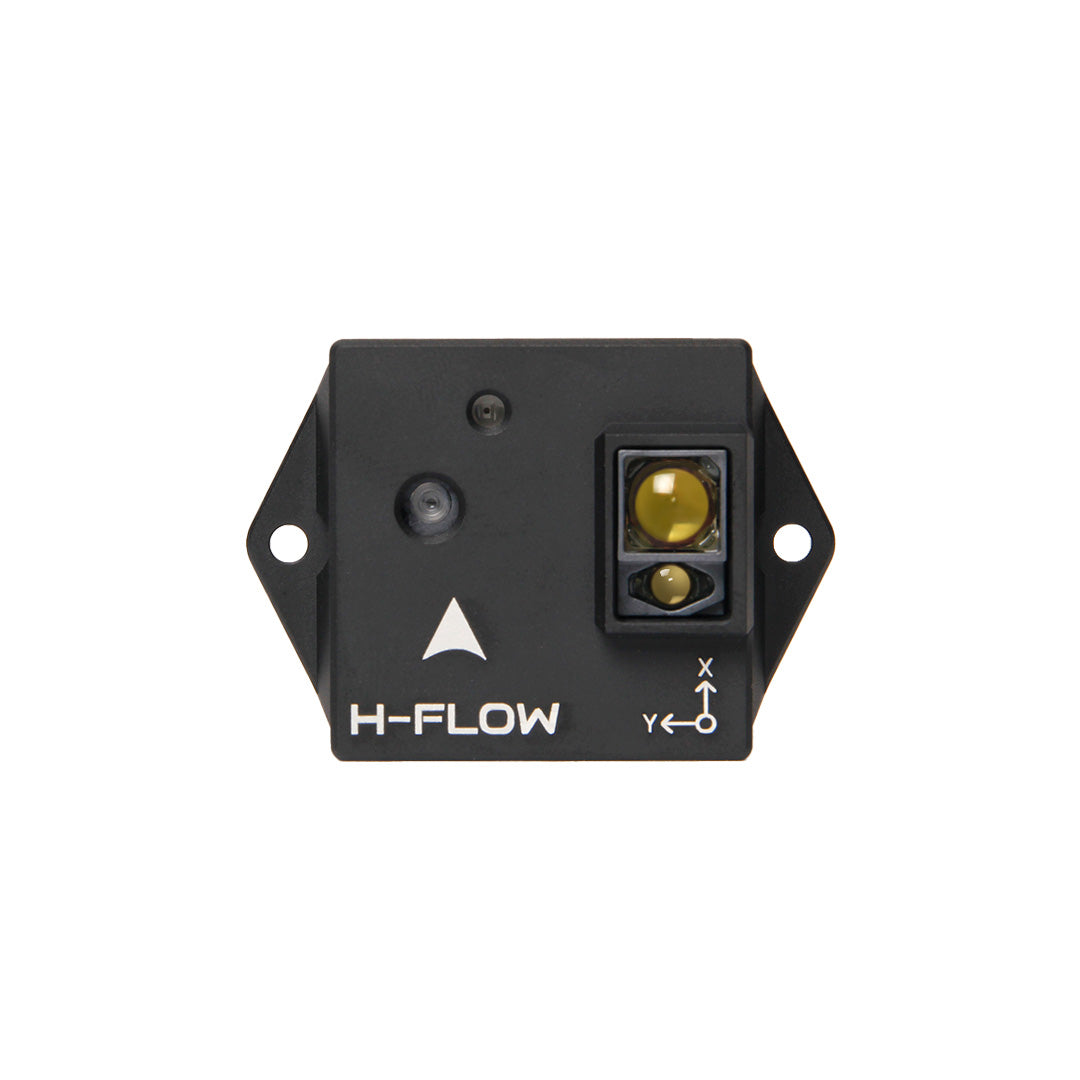
Holybro H-Flow
More images
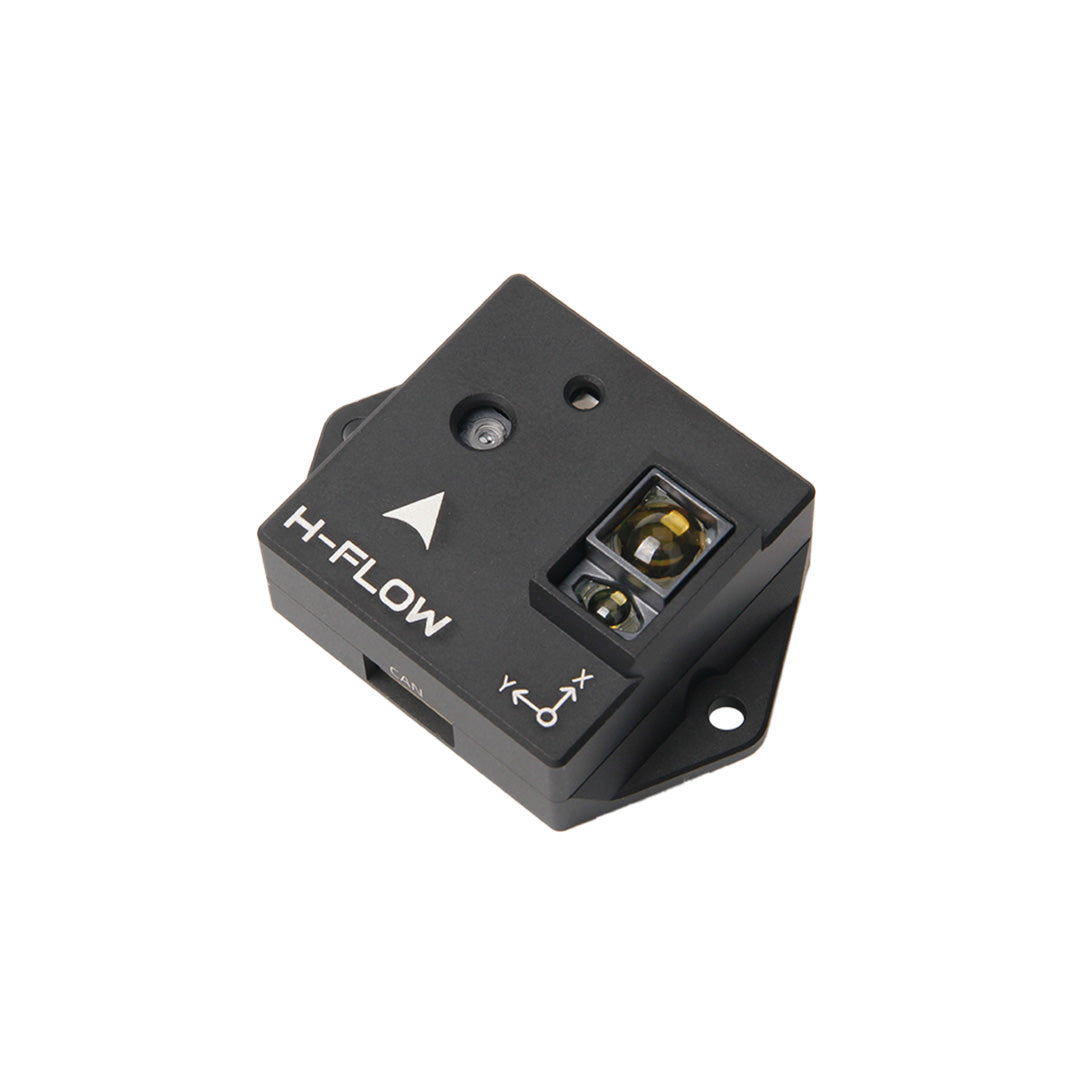
H-Flow — side
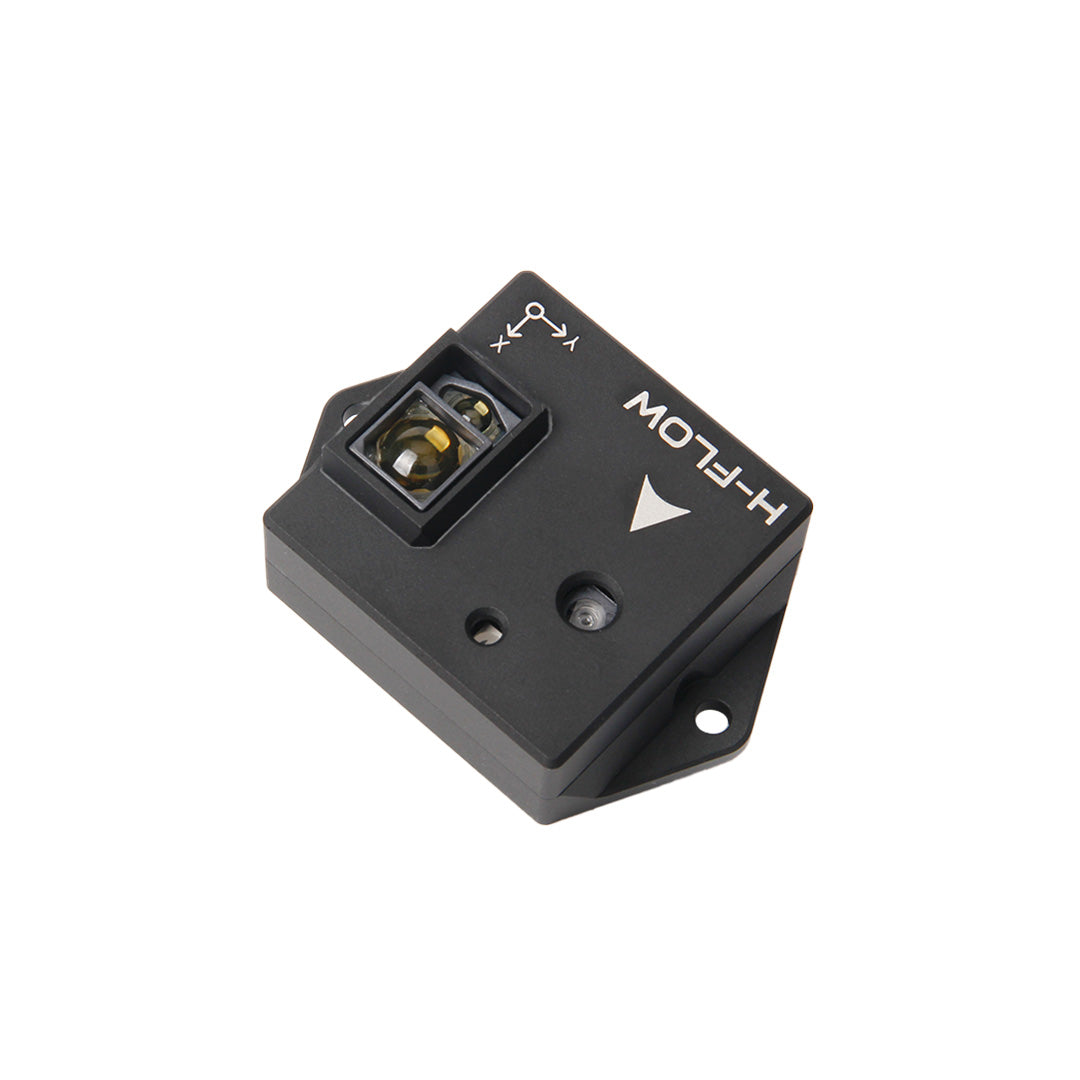
H-Flow — bottom / sensor
What we choose
H-Flow as a GPS aid. Not a replacement for outdoor long-range. Lens down. Clear view. First we want flow and height visible in telemetry.
What we do
- Mount H-Flow on the CAN Hub (or reserved CAN path). Lens down with a clear view.
- Set optical flow + rangefinder parameters per Holybro/ArduPilot docs.
- Test low over structured surfaces (grass/tiles): flow quality and height.
- Treat it as a GPS aid, not the only position source outdoors.
Manuals
- Holybro H-Flow — setup guide (ArduPilot)
- ArduPilot — Optical flow testing & setup
- Holybro H-Flow product
Video
Setup Optic Flow & Lidar for ArduPilot / PX4 (indoor hover) — YouTube
ArduPilot OpticalFlow fixed-point hovering — YouTube
Read next
Done when
Flow and distance show in telemetry. Near-ground Loiter/PosHold feels more stable.
Choice log
| What | H-Flow (optical flow + ToF) |
| Why | Steadier hover with weak GNSS or near the ground |
| Our pick | Via CAN Hub; see it first, use it harder later |
Photos