Pixhawk 6X Mini — the brain of the build
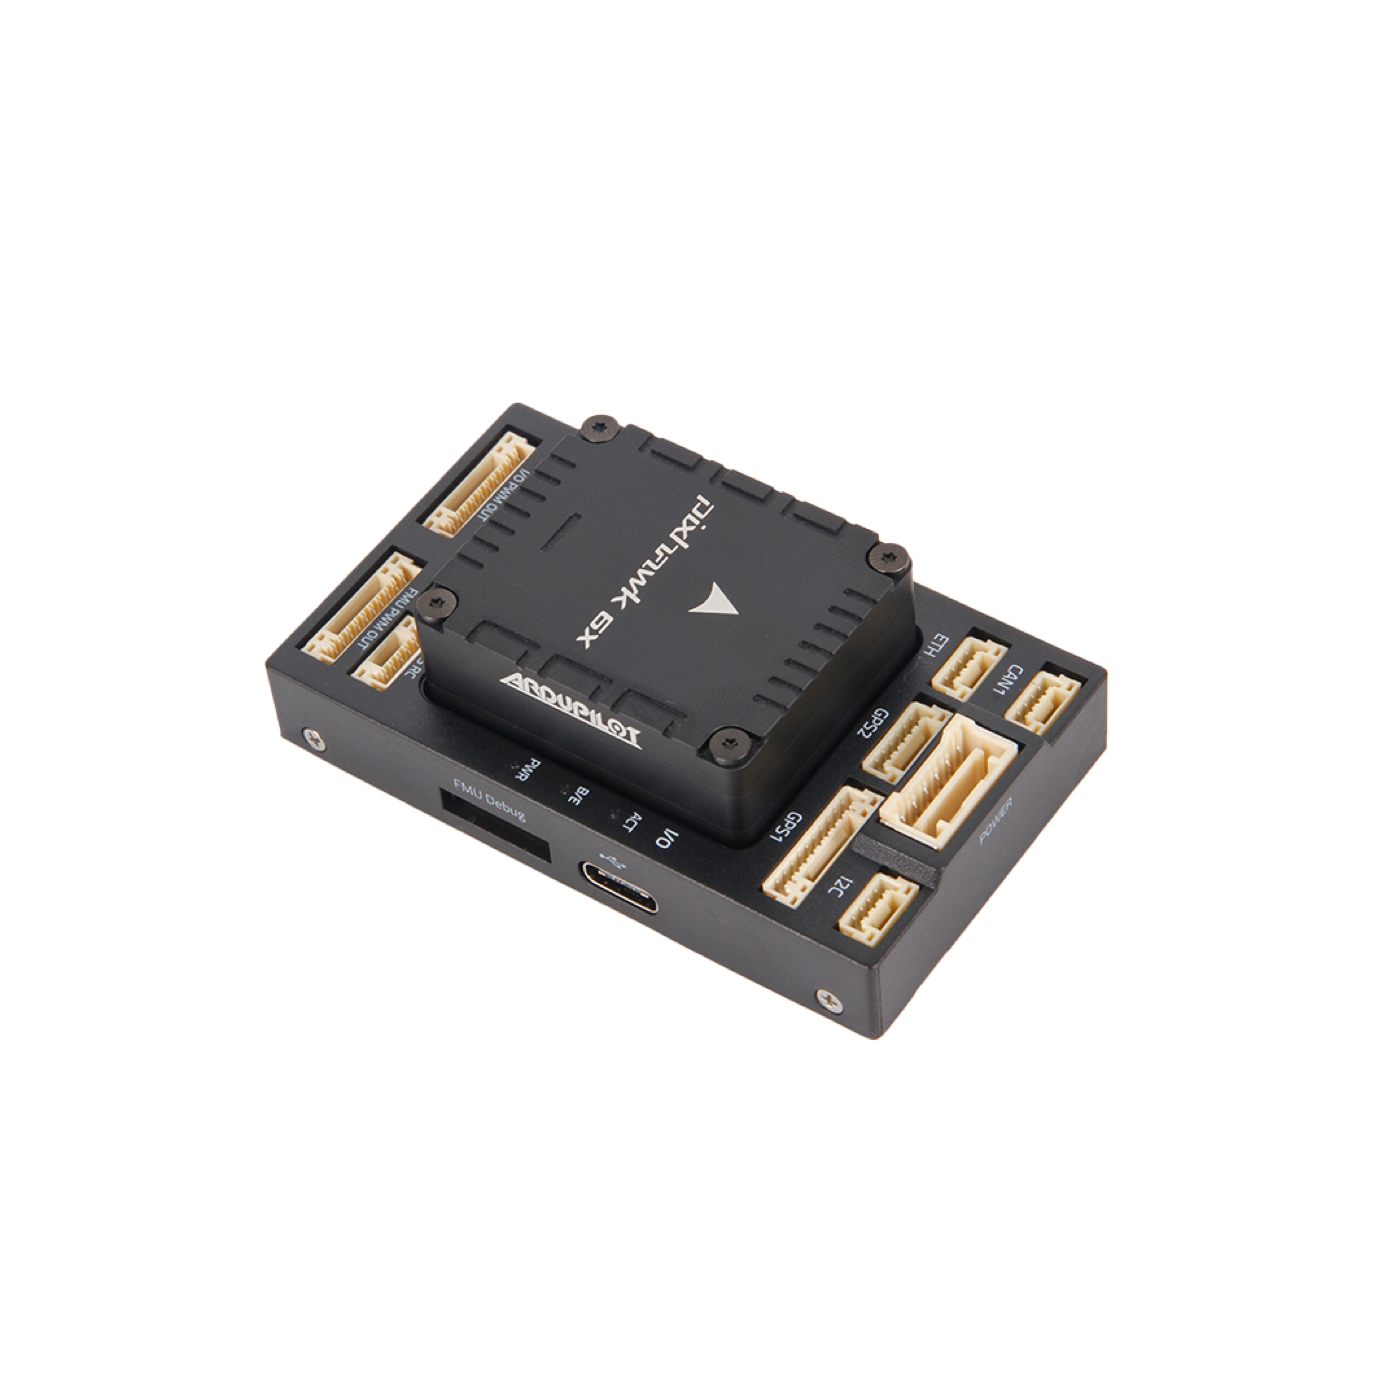
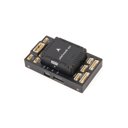
Holybro Pixhawk 6X on Mini baseboard — FMUv6X, 30.5 mm stack
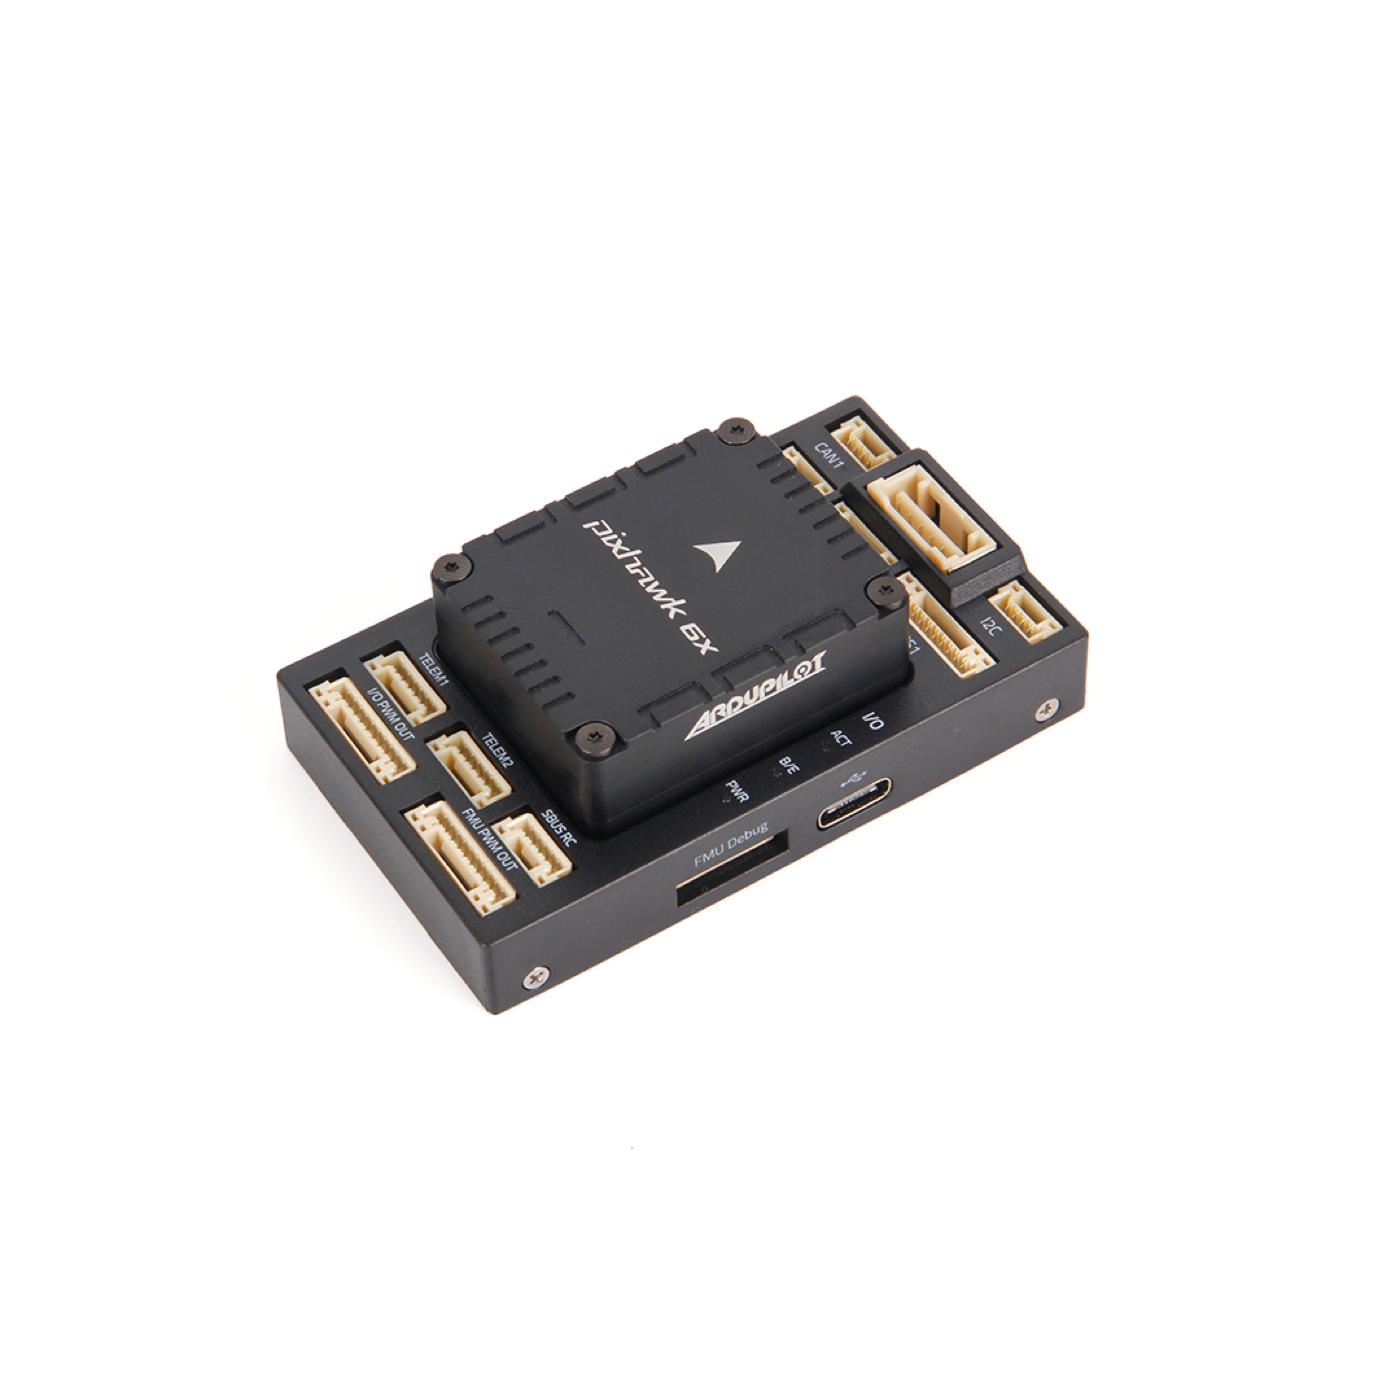
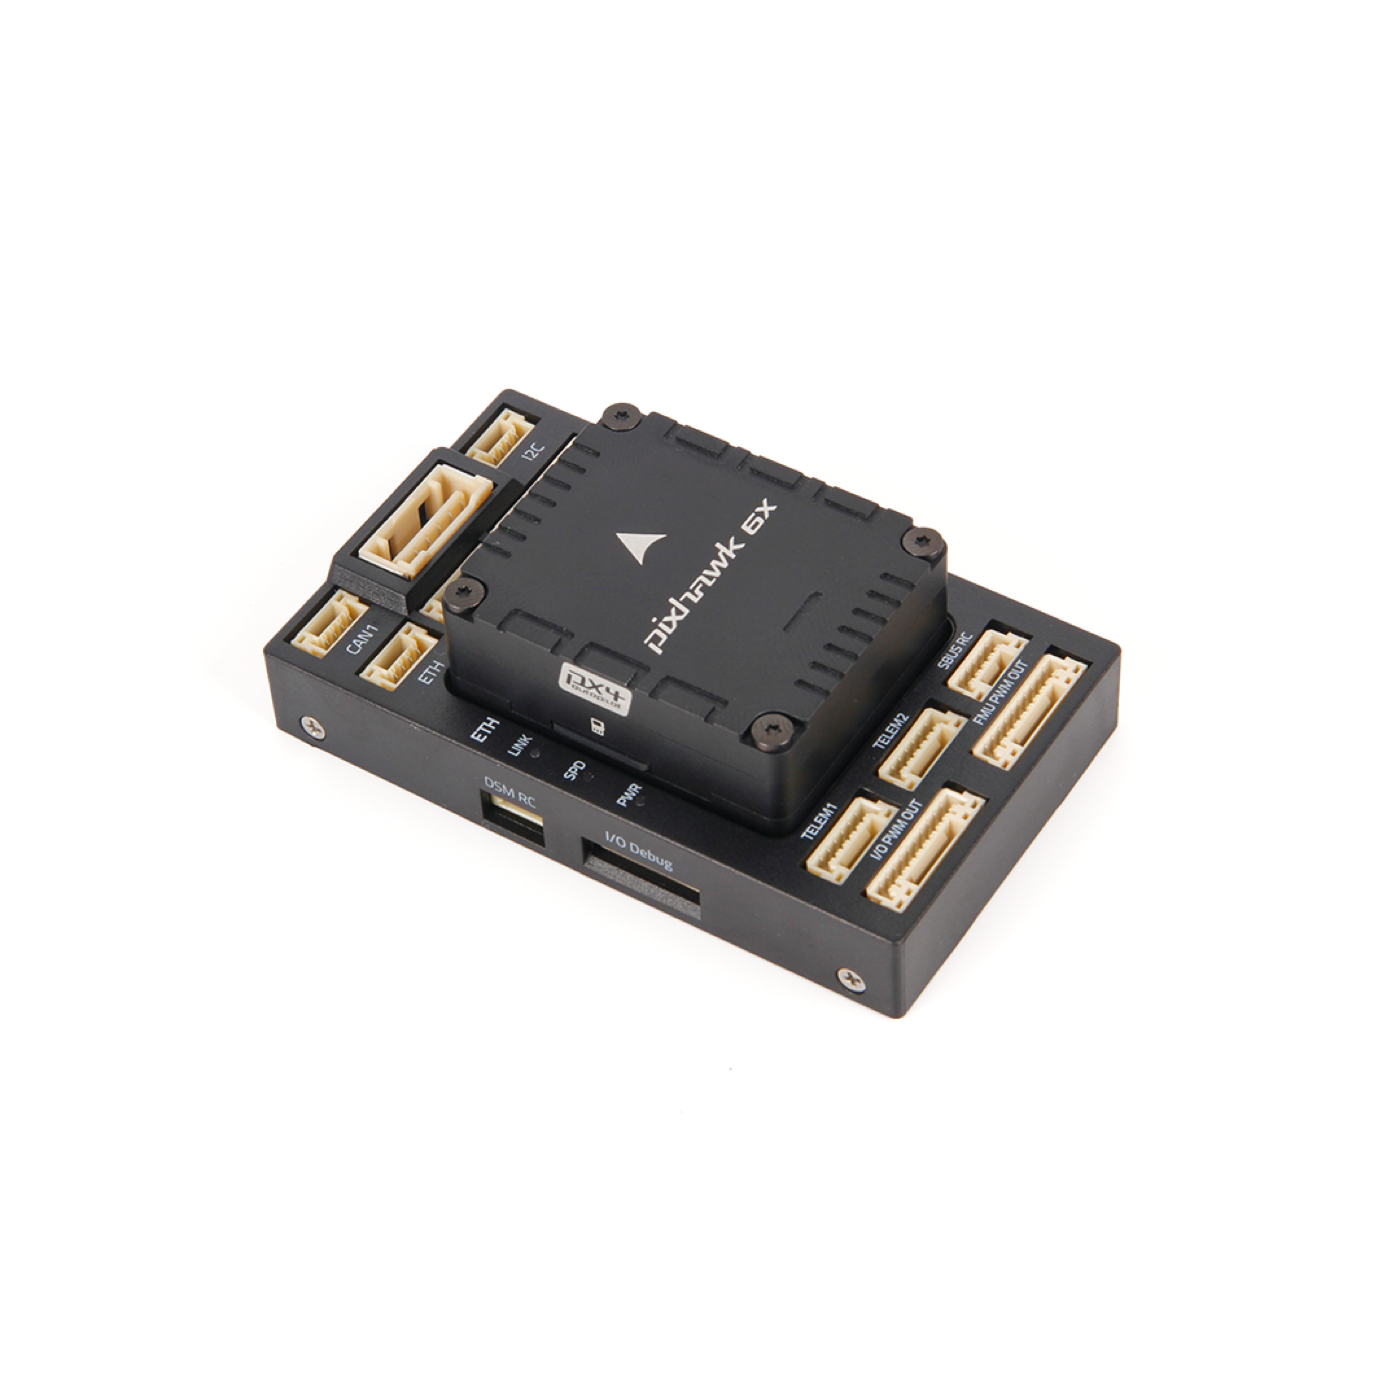
Compact I/O board — enough ports for what we finish now
We need an autopilot that can run ArduPilot, has triple IMUs, and fits the AOS UL8 V5. So we use the Pixhawk 6X Mini + PM02D: the same FMUv6X computer as Standard 6X, on a light Mini baseboard (~26.5 g).
Firmware: ArduPilot Copter, target Pixhawk6X. Store: holybro.com — Pixhawk 6X (variant Mini / PM02D). Docs: overview · Mini ports · Standard v2 ports.
Why Mini, not Standard
Holybro sells one Pixhawk 6X flight-controller module (SKU 11073). You choose the baseboard:
| Pixhawk 6X (Standard) | Pixhawk 6X Mini (this build) | |
|---|---|---|
| FC module | Same FMUv6X (STM32H753, triple IMU, dual baro, Ethernet PHY) | Same |
| Baseboard | Standard v2A / v2B (aluminum) | Mini |
| Baseboard size | ~52.4 × 102 × 16.7 mm | ~43.4 × 72.8 × 14.2 mm |
| Baseboard weight | ~51–72 g (source-dependent) | ~26.5 g |
| Typical use | Larger drones, many peripherals | Compact long-range / FPV-style frames |
| Ports | Full Standard set | Reduced — see matrix below |
| Mount | Larger footprint | 30.5 mm stack-friendly, fits AOS UL8 V5 |
| Kit we bought | — | Mini + PM02D digital power module |
In short: the “brain” is identical; Mini is the compact baseboard. Full port matrix: ports-vergelijking.md.
(These are Pixhawk 6X specs, not 6C — 6C is the cheaper line with less IMU redundancy.)
What we do
- Soft-mount on 30.5 mm in the UL8 (X-Cell).
- Flash via Mission Planner → Pixhawk6X (firmware).
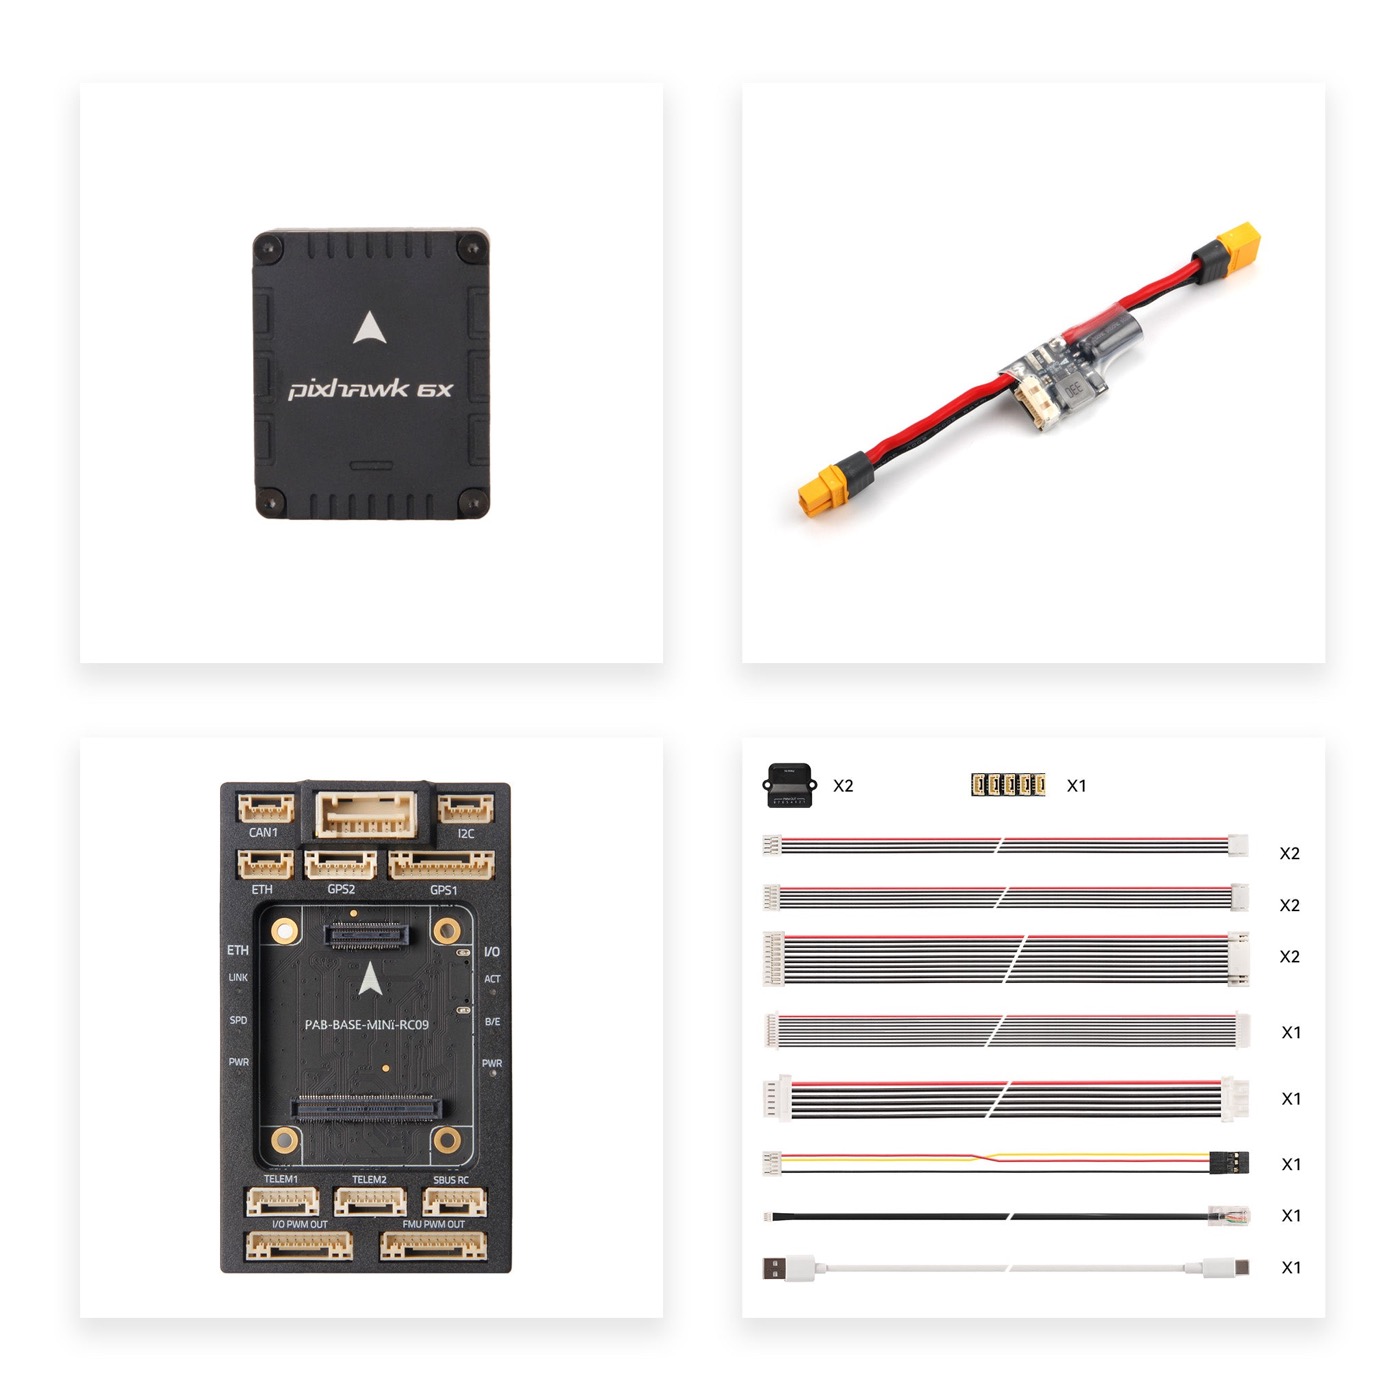
- Cables from the Mini cable set per the locked mapping below.
- POWER1 → PM02D; TELEM2 → ELRS; CAN1 → hub; GPS2 → Micro M9N.
- Safety: Micro M9N has no button →
BRD_SAFETY_DEFLT = 0(or you cannot arm).
Details: ports & wiring · step 2 — FC & power.
Processors & sensors — what they do
Specs below match Holybro’s current Rev8 shipping; older boards may be Rev3/4.
The two processors
| Chip | Role | What ArduPilot uses it for |
|---|---|---|
| FMU — STM32H753 (Cortex-M7 @ 480 MHz, 2 MB flash, 1 MB RAM) | Main computer | Runs ArduCopter (Pixhawk6X): EKF, navigation, missions, serial/CAN drivers, logging. |
| IO — STM32F103 (Cortex-M3 @ 72 MHz, 64 KB SRAM) | I/O coprocessor (IOMCU) | Drives MAIN OUT PWM to the ESCs. If the FMU hangs, the IOMCU can still output failsafe PWM. |
Short version: the H753 thinks; the F103 keeps commanding motors if things go wrong.
On-board sensors (Rev8)
| Sensor | Chip(s) | Purpose | In ArduPilot |
|---|---|---|---|
| Accel / Gyro (IMU) ×3 | 3× ICM-45686 (BalancedGyro™) | Acceleration + angular rate | Core of EKF3. Three IMUs on separate buses with isolated power: ArduPilot can fail over (EK3_IMU_MASK). Vibration isolation + IMU heater reduce motor noise. |
| Barometer ×2 | ICP20100 + BMP388/580/581 | Air pressure → relative altitude | BARO in the EKF. Dual baro = redundancy. |
| Magnetometer | BMM150 | Heading | Internal compass. Often noisy on a quad — we also use the compass on Micro M9N / F9P. |
Previous revisions (Rev3/4)
| Sensor | Chip(s) |
|---|---|
| Accel/Gyro | BMI088 or ICM-20649 · ICM-42688-P · ICM-42670-P |
| Barometer | 2× BMP388 |
| Mag | BMM150 |
ArduPilot loads the right drivers; you do not configure chip names by hand. Firmware target stays Pixhawk6X.
How this ties to ArduPilot
- ArduPilot runs on the FMU (H753) — not on the sensor chips.
- IMUs + baro + mag feed EKF3. GPS / optical flow (H-Flow) refine position.
- Redundancy (3× IMU, 2× baro) is why we picked 6X over 6C.
- External sensors use UARTs/CAN on the Mini baseboard — see ports & wiring.
- Always flash the matching build: Mission Planner → Pixhawk6X · ArduPilot + ELRS.
Holybro: Pixhawk 6X overview · ArduPilot: Pixhawk 6X.
I/O & ports — what they are (and what we use)
Holybro’s feature list mostly describes the Standard baseboard. The Mini omits some connectors; the FC module is the same.
PWM outputs (motors / servos)
| Holybro spec | Meaning | Our build |
|---|---|---|
| 16× PWM servo outputs | 8× MAIN OUT (IOMCU) + 8× AUX OUT (FMU) | MAIN OUT → Pacer 60A V2 → 4× F100 (+ LR8 props). AUX kept spare. |
| 3.3 V / 5 V signal mode | PWM logic level; switching needs a baseboard mod | Keep stock — no mod. Pacer accepts FC PWM/DShot. |
Classic RC inputs
| Spec | Meaning | Our build |
|---|---|---|
| DSM / Spektrum | Spektrum satellite | Unused. |
| PPM / S.Bus | Classic RX; on Mini as SBUS RC | Unused. RC is ELRS CRSF on a UART. |
| Analog/PWM RSSI + S.Bus out | RSSI + SBUS pass-through | Unused. |
Why not SBUS? ExpressLRS + XR4 speaks CRSF on a full UART (setup) — lower latency and telemetry back to the TX16S.
Serial ports (UARTs)
Mini has TELEM1 + TELEM2 only (no TELEM3, no UART4&I2C combo). GPS1/GPS2 are serial too, but dedicated connectors.
| Port | Role | Notes | Our build (ArduPilot) |
|---|---|---|---|
| TELEM1 | General UART | Full flow-control; separate 1.5 A 5 V limit | LD-06 — SERIAL1, PROTOCOL=11, baud 230400 |
| TELEM2 | General UART | Full flow-control | XR4 ELRS — SERIAL2, PROTOCOL=23 (CRSF) |
| TELEM3 | Extra UART | — | Not on Mini |
| UART4 + I2C + GPIO | Combo on Standard | — | Not on Mini |
| GPS1 | 10-pin (UART + I2C + safety/buzzer) | — | Empty (F9P = DroneCAN → GPS1_TYPE=9) |
| GPS2 | 6-pin (UART + I2C) | — | Micro M9N — SERIAL4 / GPS2_TYPE=1 |
One device per UART. Pick protocol per SERIALn_PROTOCOL.
I2C · Ethernet · SPI · CAN · Power
| Spec | Our build |
|---|---|
| 1× I2C (4-pin) | Spare. Compass already on GPS2/M9N; PM02D uses POWER1. |
| 100 Mbps Ethernet | Spare — see later. Not needed until we can fly safely. |
| SPI | No connector on Mini. |
| CAN | CAN1 → CAN Hub → F9P + H-Flow. CAN2 not on Mini. |
| POWER (SMBus) | POWER1 only → PM02D. POWER2 not on Mini. |
| AD & IO | Not on Mini. |
| Debug (FMU / IO) | Firmware debug only; day-to-day flash via USB-C. |
Summary: our locked mapping
POWER1 ──► PM02D ◄── battery           (digital PM / SMBus)
TELEM1 ──► LD-06                       (LiDAR / proximity)
TELEM2 ──► XR4 ◄── TX16S               (ELRS CRSF, not SBUS)
GPS2   ──► Micro M9N                   (GPS + compass, 6-pin)
GPS1   ──► (empty)                     (F9P = DroneCAN, not this jack)
CAN1   ──► Hub ──► F9P + H-Flow        (RTK + optical flow)
MAIN   ──► Pacer ──► 4× F100           (PWM/DShot)
I2C / ETH / AUX OUT / SBUS/DSM ──► spare or unused on purpose
Port reservation (locked)
Fixed assignment. Change only via docs update.
| Port | ArduPilot | Device | Docs | |
|---|---|---|---|---|
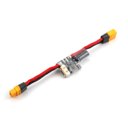 |
POWER1 | digital PM | PM02D | power + I2C telem |
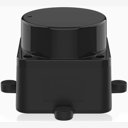 |
TELEM1 | SERIAL1 | LD-06 | PROTOCOL=11, baud 230400 |
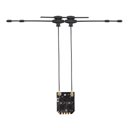 |
TELEM2 | SERIAL2 | XR4 ELRS | CRSF PROTOCOL=23 · setup |
 |
GPS1 | SERIAL3 | empty | F9P via CAN (GPS1_TYPE=9) |
 |
GPS2 | SERIAL4 | Micro M9N | GPS + compass (GPS2_TYPE=1) |
 |
CAN1 | DroneCAN | CAN Hub → F9P + H-Flow | mount: 07 |
   |
MAIN OUT | PWM / DShot | Pacer 60A V2 → F100 ×4 | props: LR8×4.2×3 |
 |
USB-C (module) | SERIAL0 | GCS / flash | Mission Planner |
|
I2C / ETH / AUX | — | spare | — |
|
SBUS RC / DSM | — | unused | RC via XR4 on TELEM2 |
Not on Mini: POWER2 · TELEM3 · CAN2 · UART4&I2C · SPI · AD&IO · USB JST-GH.
POWER1 ──► PM02D ◄── 6S2P battery
TELEM1 ──► LD-06
TELEM2 ──► XR4 ◄── TX16S
GPS2   ──► Micro M9N
GPS1   ──► (empty)
CAN1   ──► Hub ──┬─► F9P Helical
                 └─► H-Flow
MAIN   ──► Pacer ──► 4× F100 (+ LR8 props)
I2C / ETH / AUX ──► spare
Ports — Standard vs Mini
| Connector | Standard v2 | Mini | Reservation |
|---|---|---|---|
| POWER1 | ✅ | ✅ | PM02D |
| POWER2 | ✅ | ❌ | — |
| TELEM1 | ✅ | ✅ | LD-06 |
| TELEM2 | ✅ | ✅ | XR4 |
| TELEM3 | ✅ | ❌ | — |
| GPS1 | ✅ | ✅ | empty (F9P = CAN) |
| GPS2 | ✅ | ✅ | Micro M9N |
| CAN1 | ✅ | ✅ | Hub + F9P + H-Flow |
| CAN2 | ✅ | ❌ | — |
| UART4 & I2C | ✅ | ❌ | — |
| I2C (4-pin) | ✅ | ✅ | spare |
| SPI | ✅ | ❌ | — |
| ETH | ✅ | ✅ | spare |
| USB JST-GH | ✅ | ❌ | USB-C on module |
| AD&IO | ✅ | ❌ | — |
| AUX & RSSI (separate) | ✅ | ❌ | — |
| RC IN / SBUS RC | ✅ RC IN | ✅ SBUS RC | unused (ELRS) |
| DSM RC | ✅ | ✅ | unused |
| MAIN OUT (8×) | ✅ | ✅ | Pacer / F100 |
| AUX OUT (8×) | ✅ | ✅ | spare |
| FMU / IO Debug | ✅ | ✅ | development |
Present on Mini
POWER1 · TELEM1 · TELEM2 · GPS1 · GPS2 · CAN1 · I2C · ETH · DSM RC · SBUS RC · MAIN OUT · AUX OUT · debug ports · USB-C on the FC module.
Missing on Mini (vs Standard)
POWER2 · TELEM3 · CAN2 · UART4&I2C combo · SPI · AD&IO · USB JST-GH · separate AUX&RSSI block.
Safety switch
Our Micro M9N has no safety button. Without a switch set BRD_SAFETY_DEFLT = 0 or you stay in the safety state (cannot arm). Wiki: Safety Switch. A discrete switch is optional later — not required for first flight.
Local docs
- ports-vergelijking.md
- holybro-mini-baseboard-ports.md
- holybro-baseboard-v2-ports.md
- Other Holybro/PX4 snapshots +
media/
Read next
- PM02D — POWER1
- Mini cable set — connectors
- Ports & wiring — overview map
- AOS UL8 V5 · TX16S · Step 2
ArduPilot wiki
- Pixhawk 6X — board & ports
- Loading firmware
- Mounting the flight controller
- Accelerometer calibration
- Configuring hardware
- Initial setup
Reviews: Pixhawk 6 vs 6C vs 6X vs Mini · JOUAV FC guide · Discourse: Pixhawk vs solder FC.
Choice log
| What | Holybro Pixhawk 6X Mini + PM02D (FMUv6X) |
| Why | Triple IMU, IOMCU failsafe, fits 30.5 mm soft-mount on UL8 |
| Our pick | Mini over Standard (weight/size); 6X over 6C (redundancy) |
Product Info
Pixhawk 6X
- Handle:
pixhawk-6x - Vendor: PCBA
- Product type: Flight Controller
- Store URL: https://holybro.com/products/pixhawk-6x
Description
Key Design Points Redundancy: 3x ICM-45686 IMU sensors ( ±32g) with BalancedGyro™ technology & 2x Barometer sensors High-performance STM32H753 Processor with a clock speed of up to 480 MHz Modular flight controller: separated IMU, FMU, and Base system connected by a 100-pin & a 50-pin Pixhawk® Bus connector. Triple redundancy domains: Completely isolated sensor domains with separate buses and separate power control All-New advanced durable vibration isolation material with resonance frequency in the higher spectrum Ethernet interface for high-speed mission computer integration. Transformerless can be achieved using 50 Ohm termination resistors at the target device ( AN2190 50 Ohm termination ). Temperature-controlled IMU board, allowing the optimum working temperature of IMUs Hardware switchable 3.3V or 5V signal mode (requires baseboard modification) Digital power module support for better voltage and current data accuracy All new Vibration Isolation Design This new vibration isolation design uses the same c ustom-formulated durable isolation material as the Pixhawk 6X Pro , instead of the traditional foam design . B acked by extensive R&D and testing , it offers optimal IMU damping characteristics with a resonance frequency in the higher spectrum, perfect for industrial and commercial drones. Note: The Rev 8 Version is supported in the PX4 1.14.3 release or later, as well as the Ardupilot 4.5.0 stable release or later. It ships with PX4 firmware by default. The user can also use the Ardupilot firmware by flashing the firmware via Mission Planner or QGroundControl. Power module comparison chart Specification Processors & Sensors FMU Processor: STM32H753 32 Bit Arm® Cortex®-M7, 480MHz, 2MB flash memory, 1MB RAM IO Processor: STM32F103 32 Bit Arm® Cortex®-M3, 72MHz, 64KB SRAM On-board sensors (Shipping Currently, Rev8) Accel/Gyro: 3x ICM-45686 (with BalancedGyro™ Technology) Barometer: ICP20100 & BMP388/580/581 Mag: BMM150 NXP EdgeLock SE050 Plug & Trust hardware secure element Electrical data Voltage Ratings: Max input voltage: 6V USB Power Input: 4.75~5.25V Servo Rail Input: 0~36V Current Ratings: Telem1 & GPS2 combined current limit: 1.5A All other ports combined current limit: 1.5A PWM Signal Voltage: Default 3.3V (Adjustable to 5V with a change onboard resistor) Operating Temperature: -25-85°C Mechanical data Dimensions Flight Controller Module: 38.8 x 31.8 x 16.8mm Standard Baseboard: 52.4 x 102 x 16.7mm ( Aluminum ) Mini Baseboard: 43.4 x 72.8 x 14.2 mm Weight Flight Controller Module: 31.3g Standard Baseboard: 72.5g ( Aluminum) Mini Baseboard: 26.5g Reference Links Full Specification Pixhawk Baseboards Ports Power Module Setup Guide Dimensions Downloads Sample Wiring Diagram Latest info on Supported Firmware. For other technical information, please visit https://docs.holybro.com/. SKU 11073 includes: Pixhawk 6X Flight Controller Module Controller + Baseboard + Power Module Set includes: Pixhawk 6X Flight Controller Module Standard Baseboard v2A/v2B or Mini Baseboard PM02D HV Power Module Cable Set Accessories: Pixhawk PWM Cable for Tekko32 4in1 ESC Standard Baseboard Mounting Plate
Variants
- Standard v2A / PM02D: $320.98 — SKU
11073+18117+15011— available=None - Standard v2B / PM02D: $320.98 — SKU
11073+18125+15011— available=None - Mini / PM02D: $286.98 — SKU
11073+18074+15011— available=None - None (FC Module Only) / FC Module Only: $166.99 — SKU
11073— available=None
Options
- Pixhawk Baseboard Version: Standard v2A, Standard v2B, Mini, None (FC Module Only)
- Power Module: PM02D, FC Module Only
Photos