
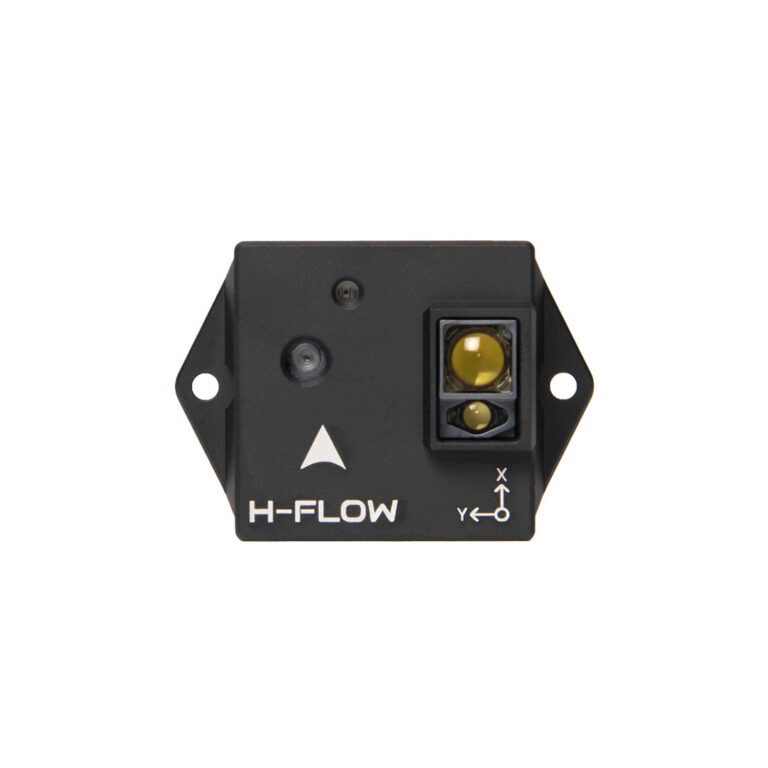
Step 5 — Low-speed sensing
Indoors and near the ground, H-Flow (optical flow + distance) helps where GPS is weak. We validate that sensor now. Hard avoidance comes later. Go back to…

Indoors and near the ground, H-Flow (optical flow + distance) helps where GPS is weak. We validate that sensor now. Hard avoidance comes later. Go back to…
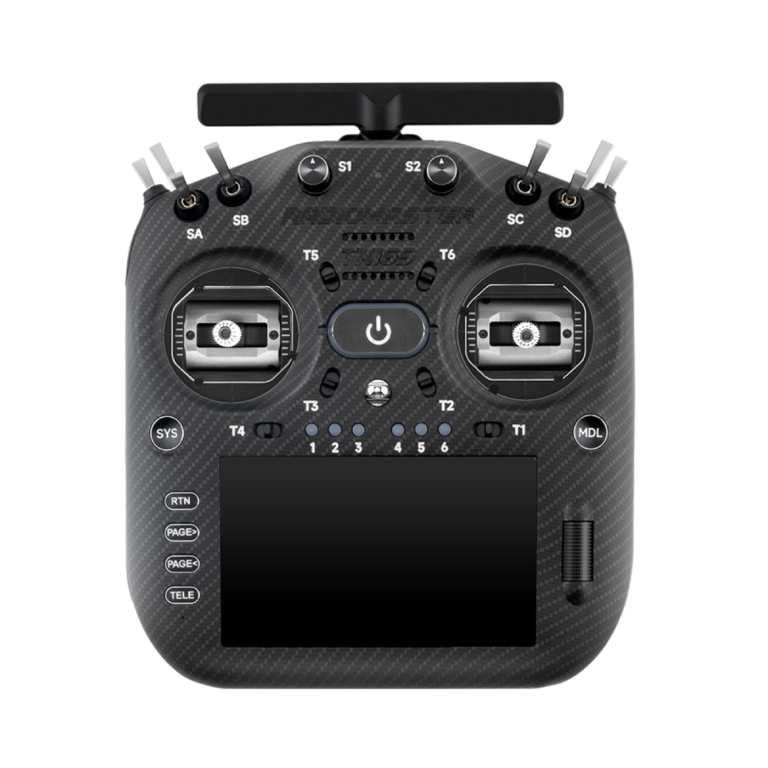
No reliable radio means no safe first flight. We link the TX16S MK3 MAX to the XR4 ELRS on TELEM2. Not on the same UART as the LiDAR. Full guide: ExpressLRS…
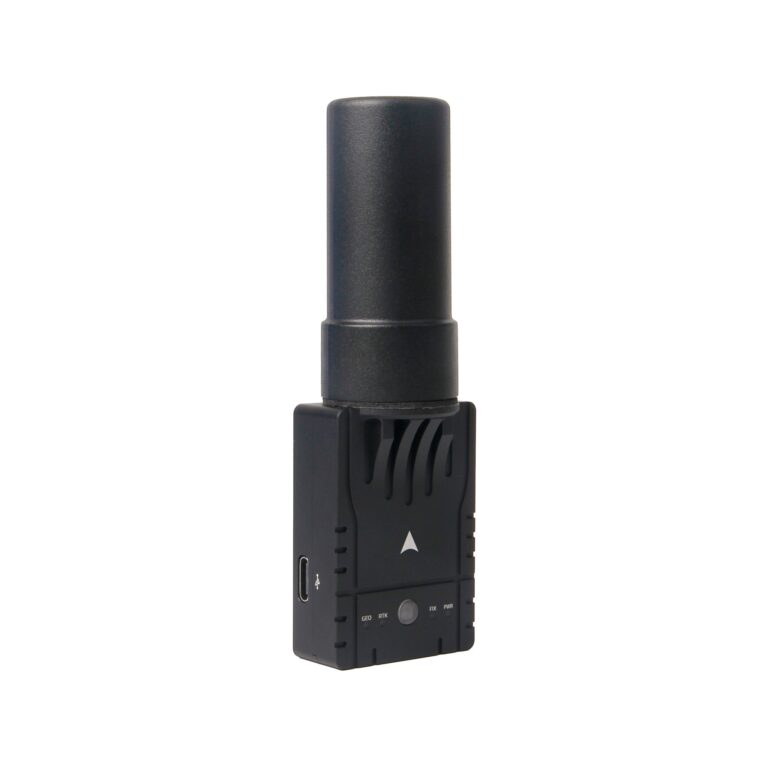
With power and FC in place (step 2), we add position and orientation. Micro M9N on GPS2. H-RTK F9P Helical and later H-Flow on the CAN Hub. Port plan: ports…
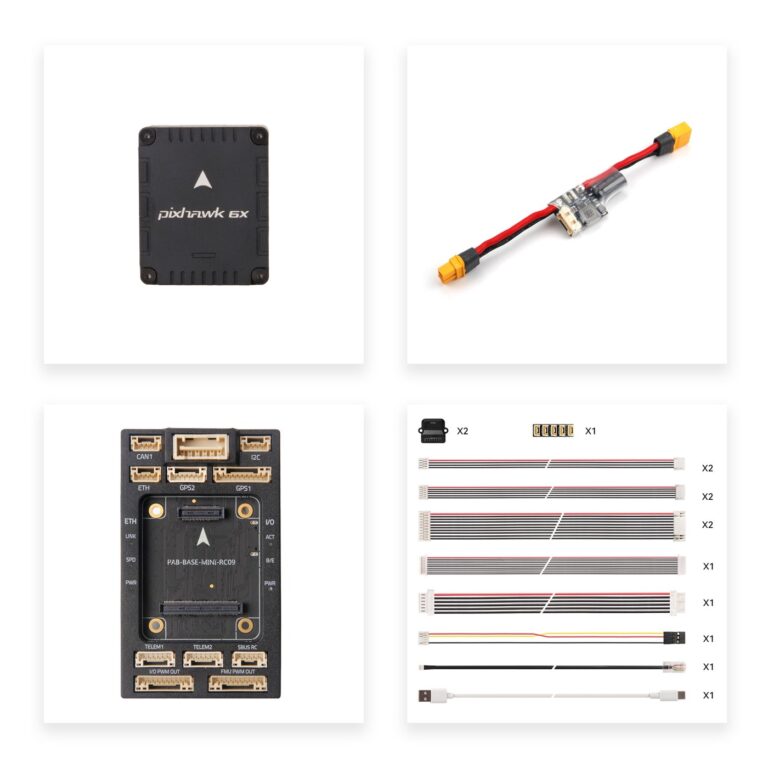
Now the frame is up, we add the nervous system: the Pixhawk 6X Mini and the PM02D. Power first. Then GPS and radio. Otherwise we debug three problems at once.
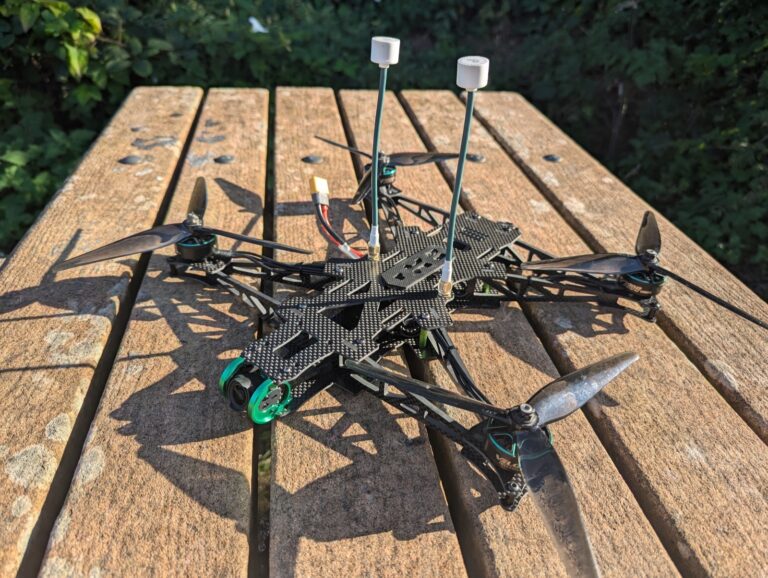
We start where every craft starts: the frame. On the AOS UL8 V5 we mount motors, ESC, stack, and later every sensor. This step is about strength, vibration,…
HQProp LR8×4.2×3 — 8″ GF nylon, CW+CCW per set
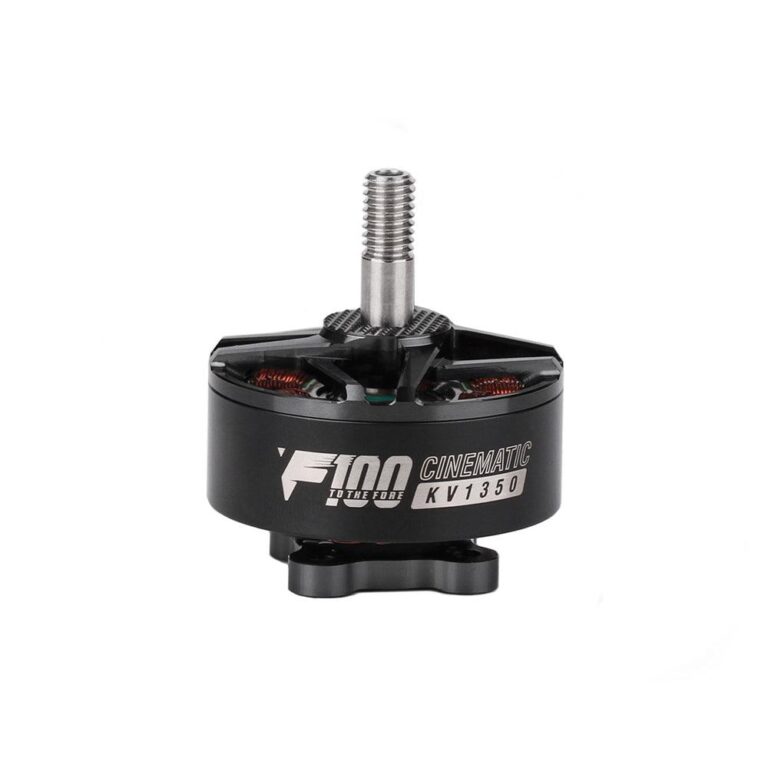
For the UL8 we need motors that fit 6S and a heavy avionics stack. So we ordered 4× T-Motor F100 1100KV. Art. 107810 · 4× € 36.95 = € 147.80 · 2026-09-06.
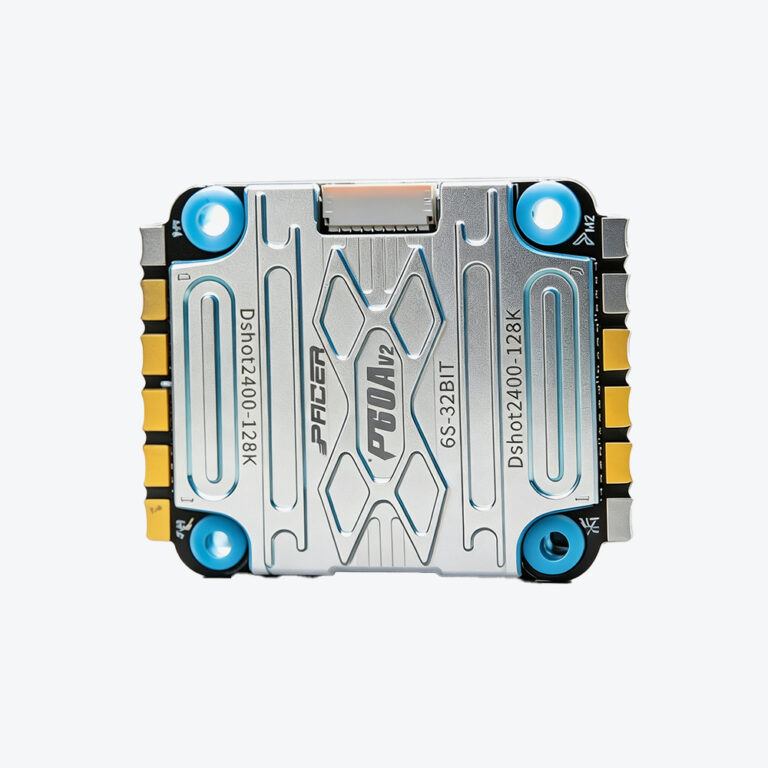
Pacer 60A V2 — 4-in-1 ESC for the UL8 stack
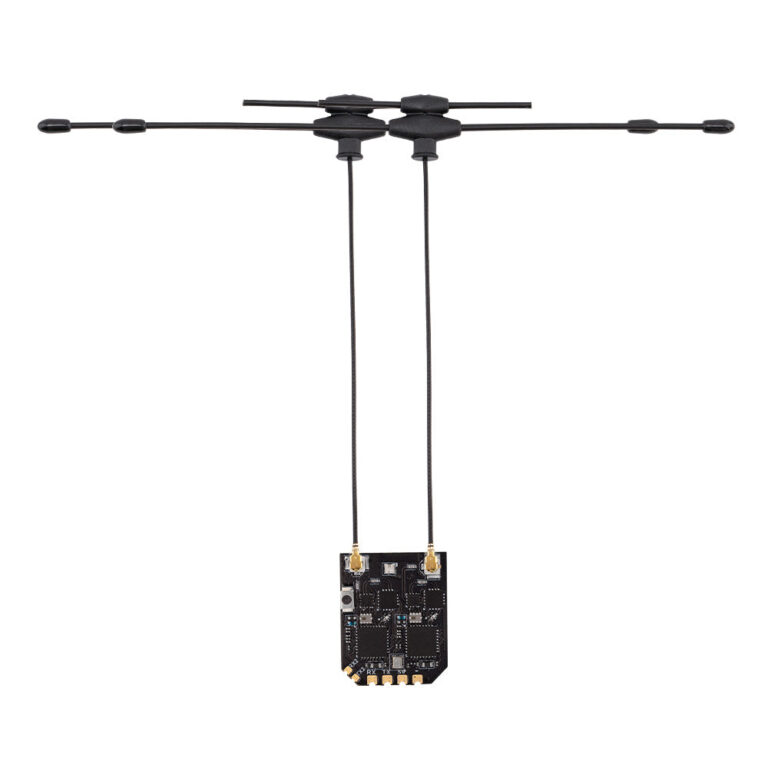
The TX16S was ready. So was the XR4. Then the beginner question (ours): how does that handset actually talk to the Pixhawk — and what’s legal in the…
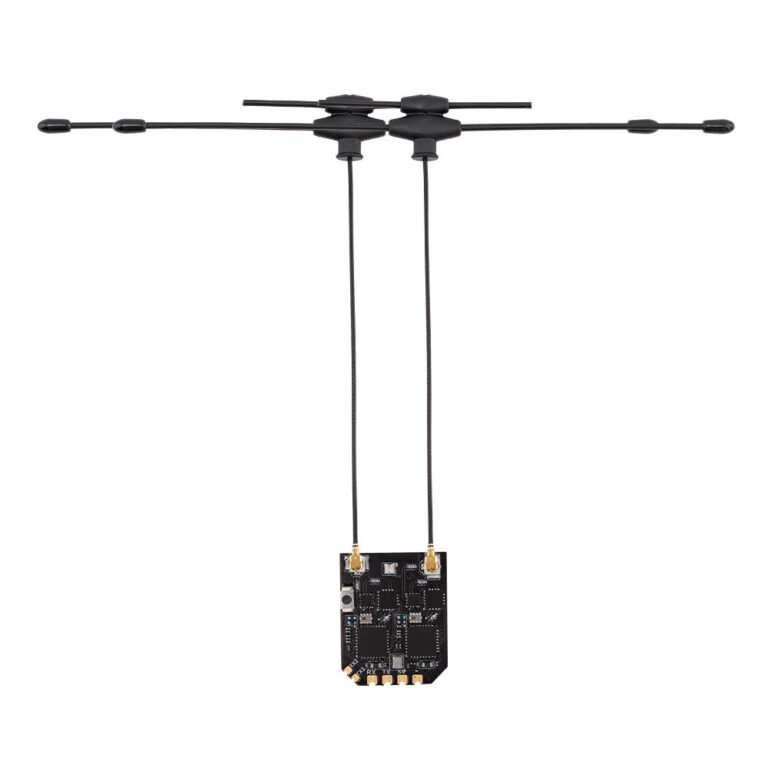
RadioMaster XR4 Gemini Xrossband — dual-band ELRS RX