Ports & wiring on the Pixhawk 6X Mini
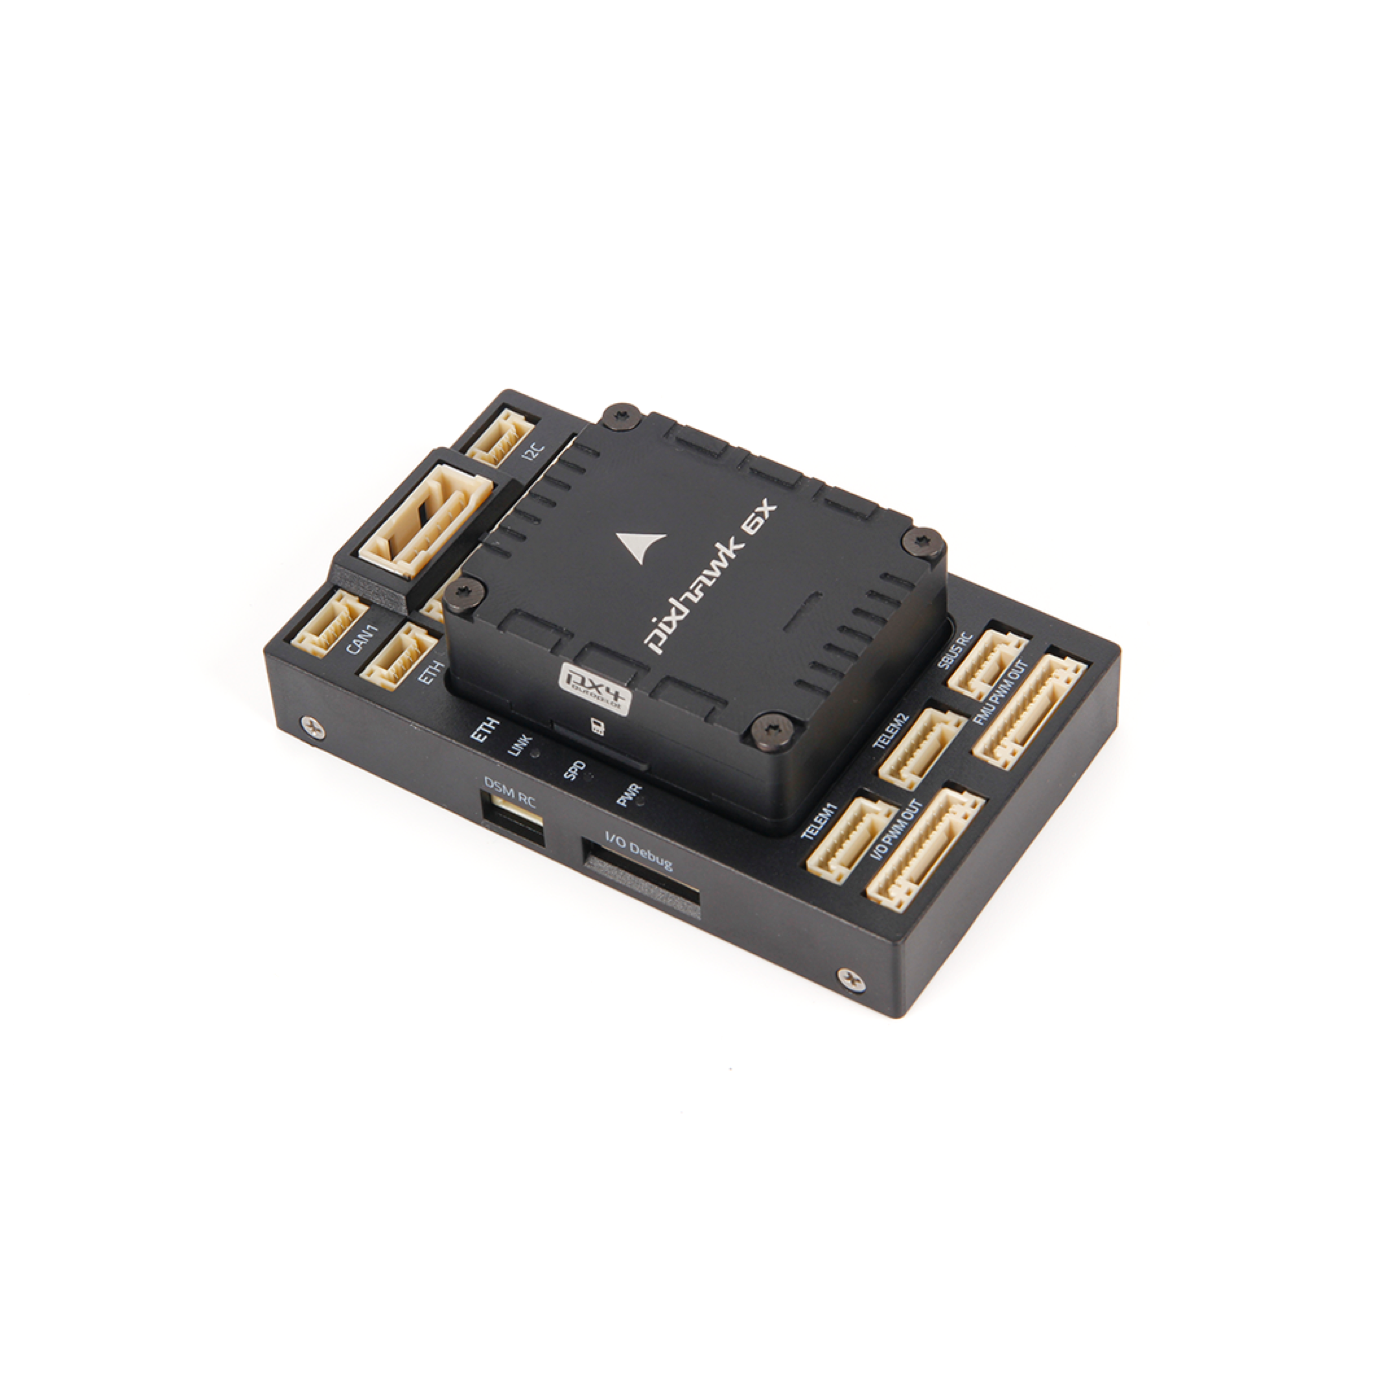
Pixhawk 6X Mini — small board, few serial ports
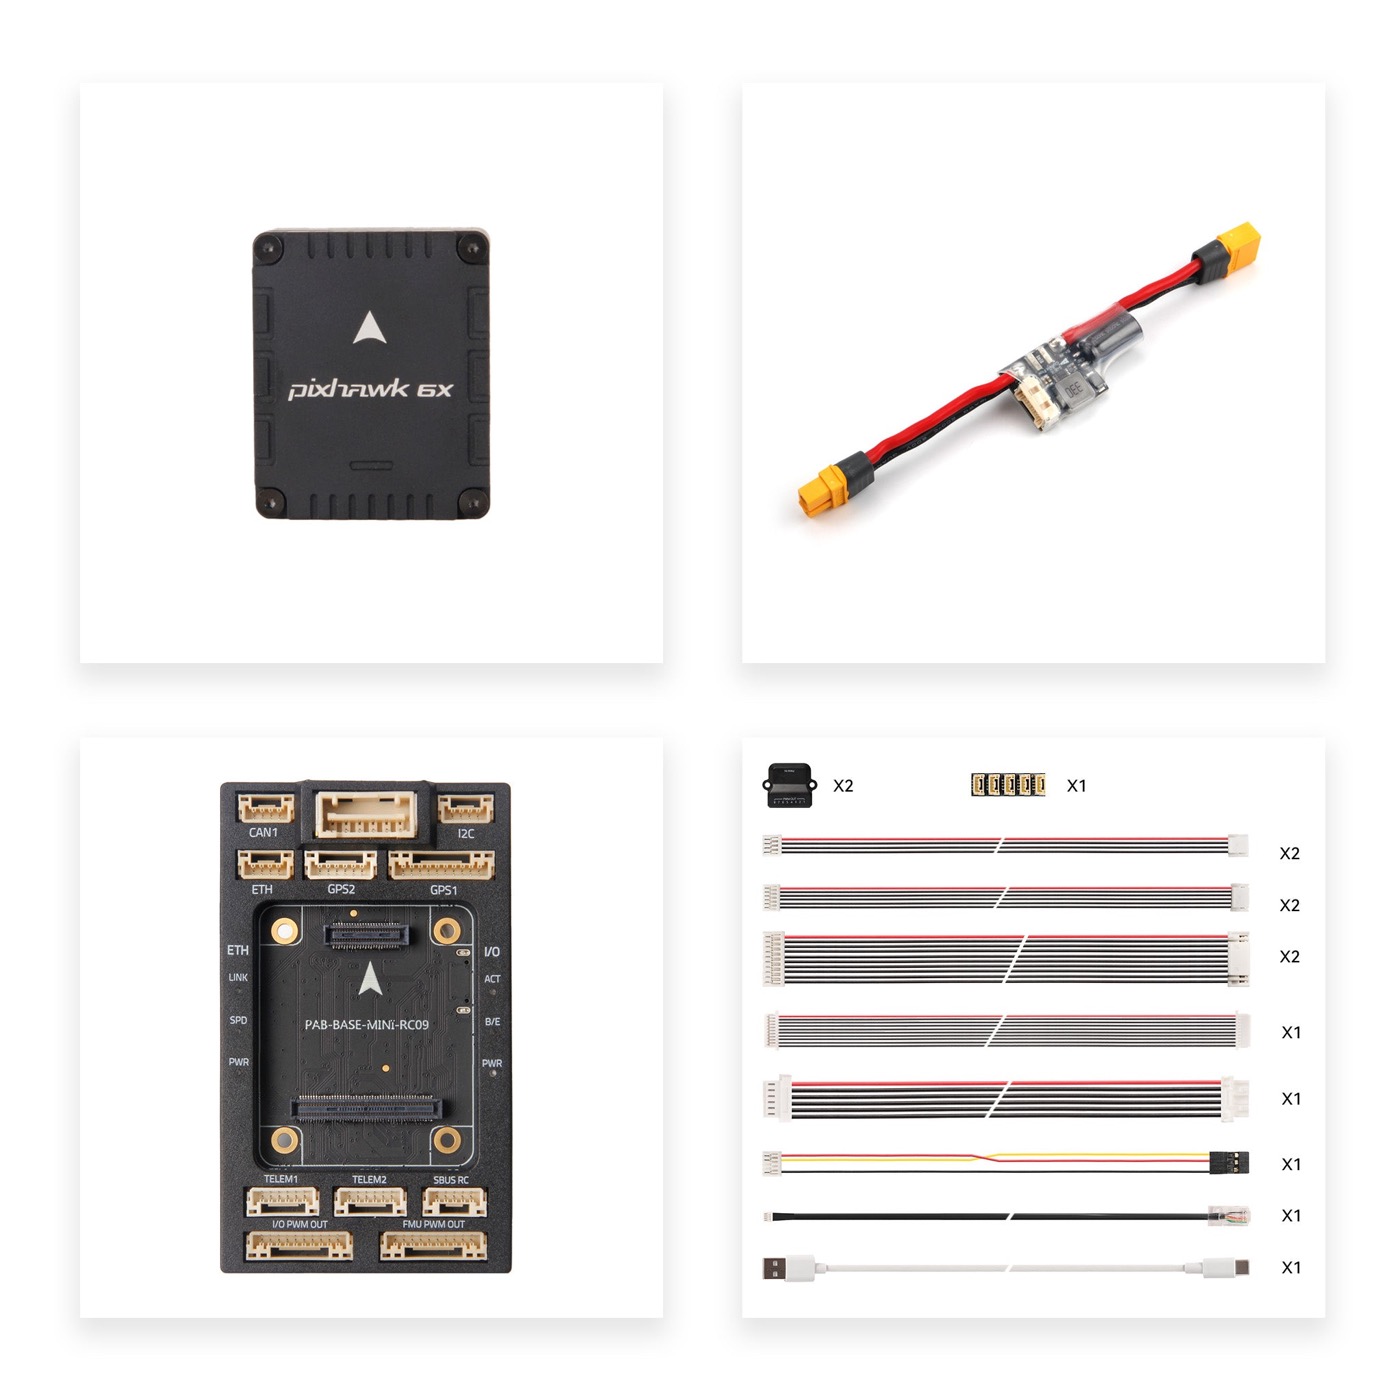
Mini baseboard: this is where the scarcity lives
We were about to put the XR4 on TELEM1 “for now”. ELRS first, everything else later — felt sensible. Then we looked at the Mini baseboard again, and at the LD-06 that also wants a UART. Two general TELEM ports. No TELEM3. Pause.
So before we solder or shove JST-GH plugs home, we lock the mapping. Otherwise radio and LiDAR fight for the same UART, and you only notice when failsafe gets weird.
Per Holybro I/O feature: Pixhawk 6X Mini — I/O & ports.
Why this matters
On a fuller Pixhawk you can sometimes “just add one more thing”. On the Mini you can’t. TELEM1 and TELEM2 are the only general UARTs. So: one device per UART. LD-06 on TELEM1. XR4 (CRSF) on TELEM2. GPS2 for the Micro M9N. F9P + H-Flow on CAN1 via the CAN Hub.
We do not “share a port quickly”. That causes failsafe trouble and a param mess nobody understands — including us three weeks later.
What we lock
The map below is locked for our build. Story first, table after.
Do not share: TELEM1 stays with LD-06; TELEM2 with ELRS.
Setup: ArduPilot + ELRS · step 4 — radio.
Peripheral overview: project intro · Optional Hardware.
Locked mapping (ArduPilot)
| Function | Port | Protocol / type |
|---|---|---|
| Battery / FC power | POWER1 via PM02D | digital (I2C) |
| UART GPS + compass | GPS2 | Micro M9N (GPS2_TYPE=1) |
| GPS1 connector | GPS1 | empty — F9P is DroneCAN (GPS1_TYPE=9) |
| CAN | CAN1 + CAN Hub | F9P Helical + H-Flow |
| ELRS (CRSF) | TELEM2 / SERIAL2 | XR4 ← TX16S |
| LiDAR proximity | TELEM1 / SERIAL1 | LD-06 (PRX1_TYPE=16) |
| Motors | MAIN OUT → Pacer | DShot/PWM |
Cabling (short)
From the Cable Design Guidelines — what we actually take with us:
- Colour: red = +, black = GND; prefer twisted pairs for data.
- CAN: CAN_H / CAN_L twisted; 120 Ω termination at bus ends (CAN Hub).
- GPS / compass: keep away from ESC, motor leads, video TX.
- Power vs signal: keep battery runs short; avoid long parallel signal beside power (EMI).
- Strain-relieve JST-GH connectors — vibration causes intermittent ghosts.
Power: power & capacitors. Signals: short and twisted where possible.
Build order
- Frame + propulsion
- FC & power
- GPS/RTK/flow
- Radio
- Flow check + LiDAR
- Config & first flight
Read next
ArduPilot: Pixhawk 6X · Serial options · FC wiring · Telemetry port · CRSF / ELRS
Choice log
| What | Fixed UART/CAN/power map on Pixhawk 6X Mini |
| Why | Mini has few ports; ELRS and LiDAR must not clash |
| Our pick | LD-06 → TELEM1 · XR4 CRSF → TELEM2 · F9P+H-Flow → CAN1 |
Photos