Power & capacitors on our UL8
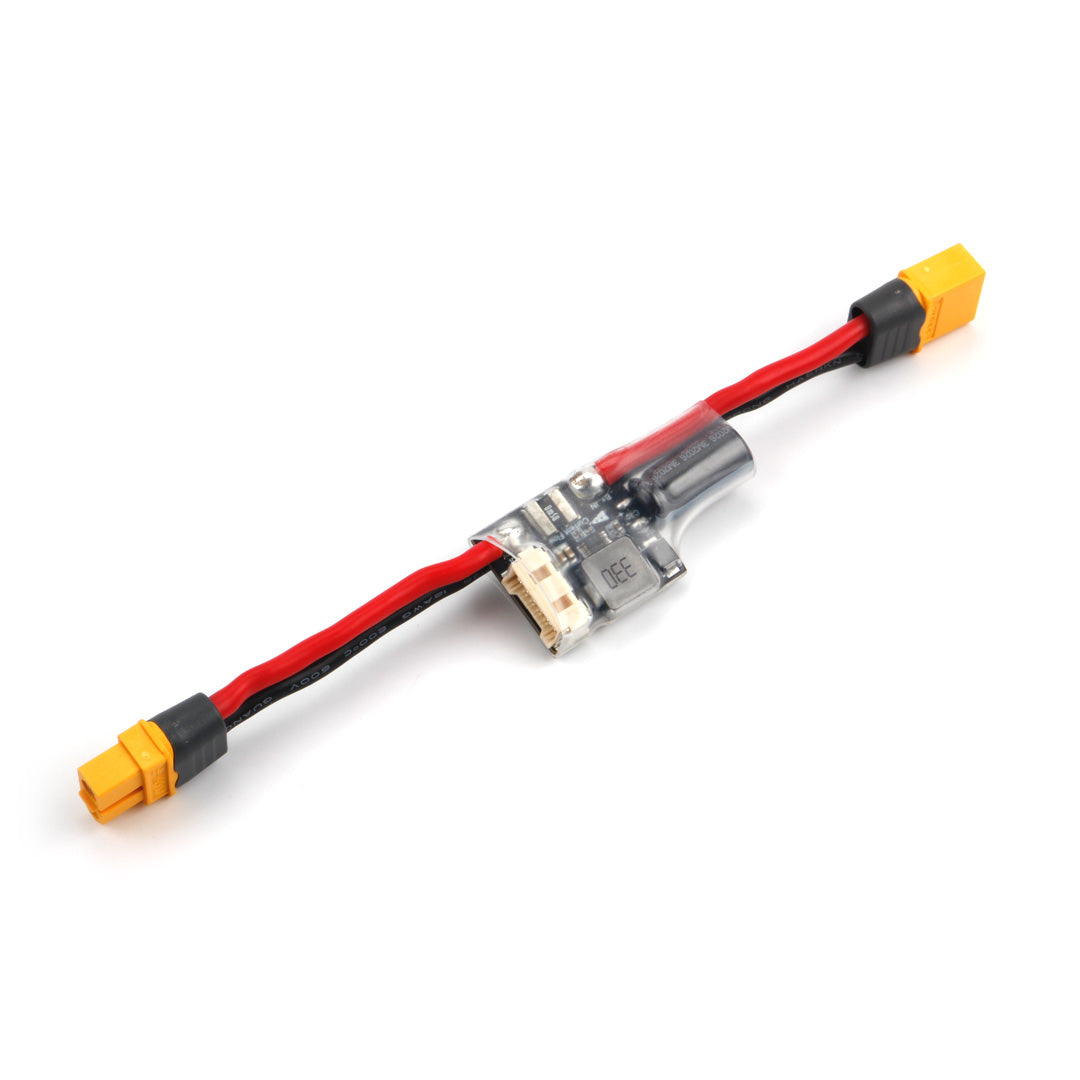
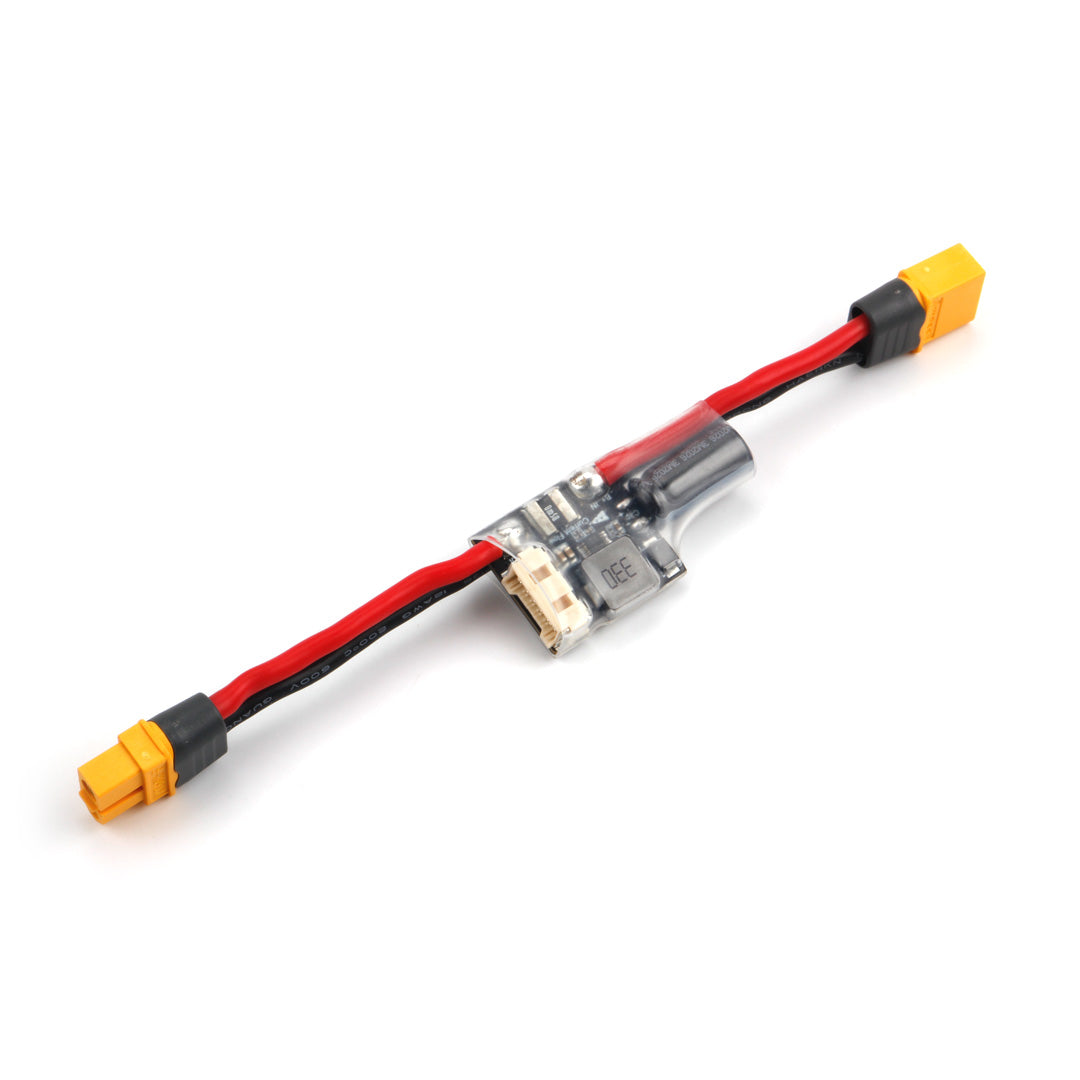
PM02D power module
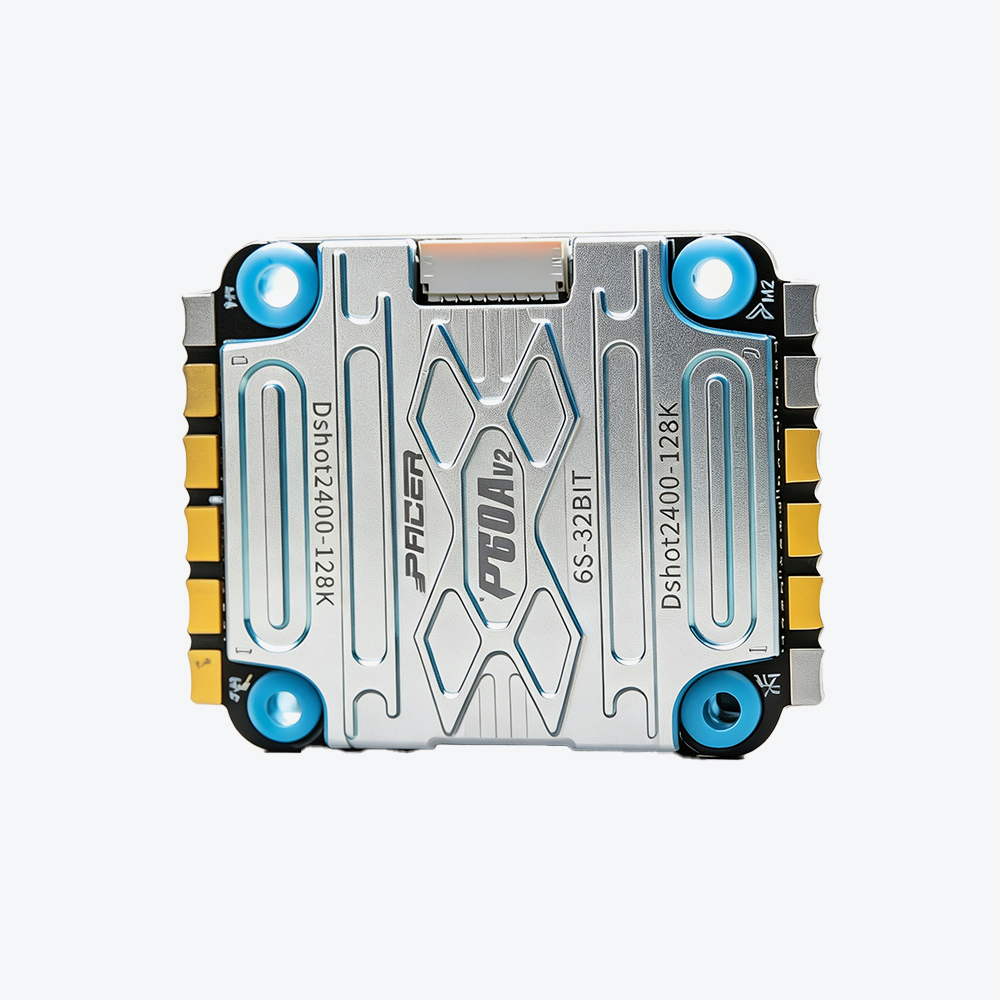
Pacer ESC — where the capacitor goes
We had the Pacer and the PM02D on the bench and briefly thought: “just feed everything through the ESC, right?” Sounds tidy. On an 8″ 6S quad with four solid motors, that is a bad idea. Motors pull spikes. The flight controller and sensors want calm power. So: how we split current — and why a low-ESR capacitor belongs on the ESC.
The problem in one line
Prop spikes do not belong on the same thin rail as the Pixhawk. And our CAN gear drinks more 5 V than “just sip from FC CAN1” can supply.
The Holybro CAN Hub has its own XT30 Power-In (2–12S). That must also come from the pack. Otherwise F9P + H-Flow only sip the thin FC 5V — until something brownouts.
We use an XT60H 1→3 Y (+ adapters where needed) from the Tattu 6S pack.
How we split it
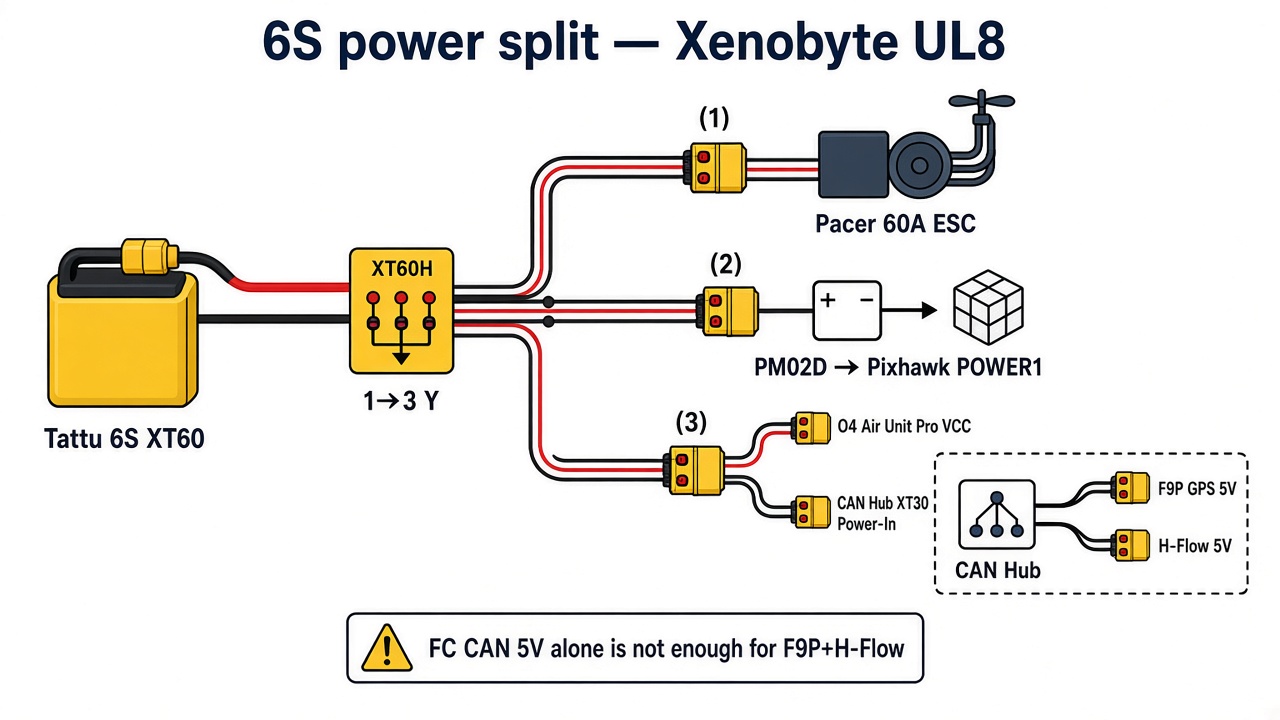
6S XT60 ── Y / adapters ──┬──► Pacer 60A V2 ──► 4× F100 (motors)
                           ├──► PM02D ──► POWER1 (Pixhawk 6X Mini)
                           ├──► DJI O4 Air Unit Pro (7.4–26.4 V)
                           └──► CAN Hub XT30 Power-In ──► 5.2 V to F9P + H-Flow
                                    ▲
                                    └── CAN data: Hub ──► Pixhawk CAN1 (signal + optional backup 5V)
- The Pacer powers motors only.
- The PM02D powers the Pixhawk 6X Mini and measures voltage/current. Not an ESC PDB.
- The O4 Pro shares the pack rail. Install: O4 install.
- CAN peripherals: F9P (~250 mA @ 5 V) + H-Flow draw too much for “FC CAN 5V alone”. Fix: XT30 on the CAN Hub (2–12S in → 5.2 V / up to 1 A per port, 3 A total).
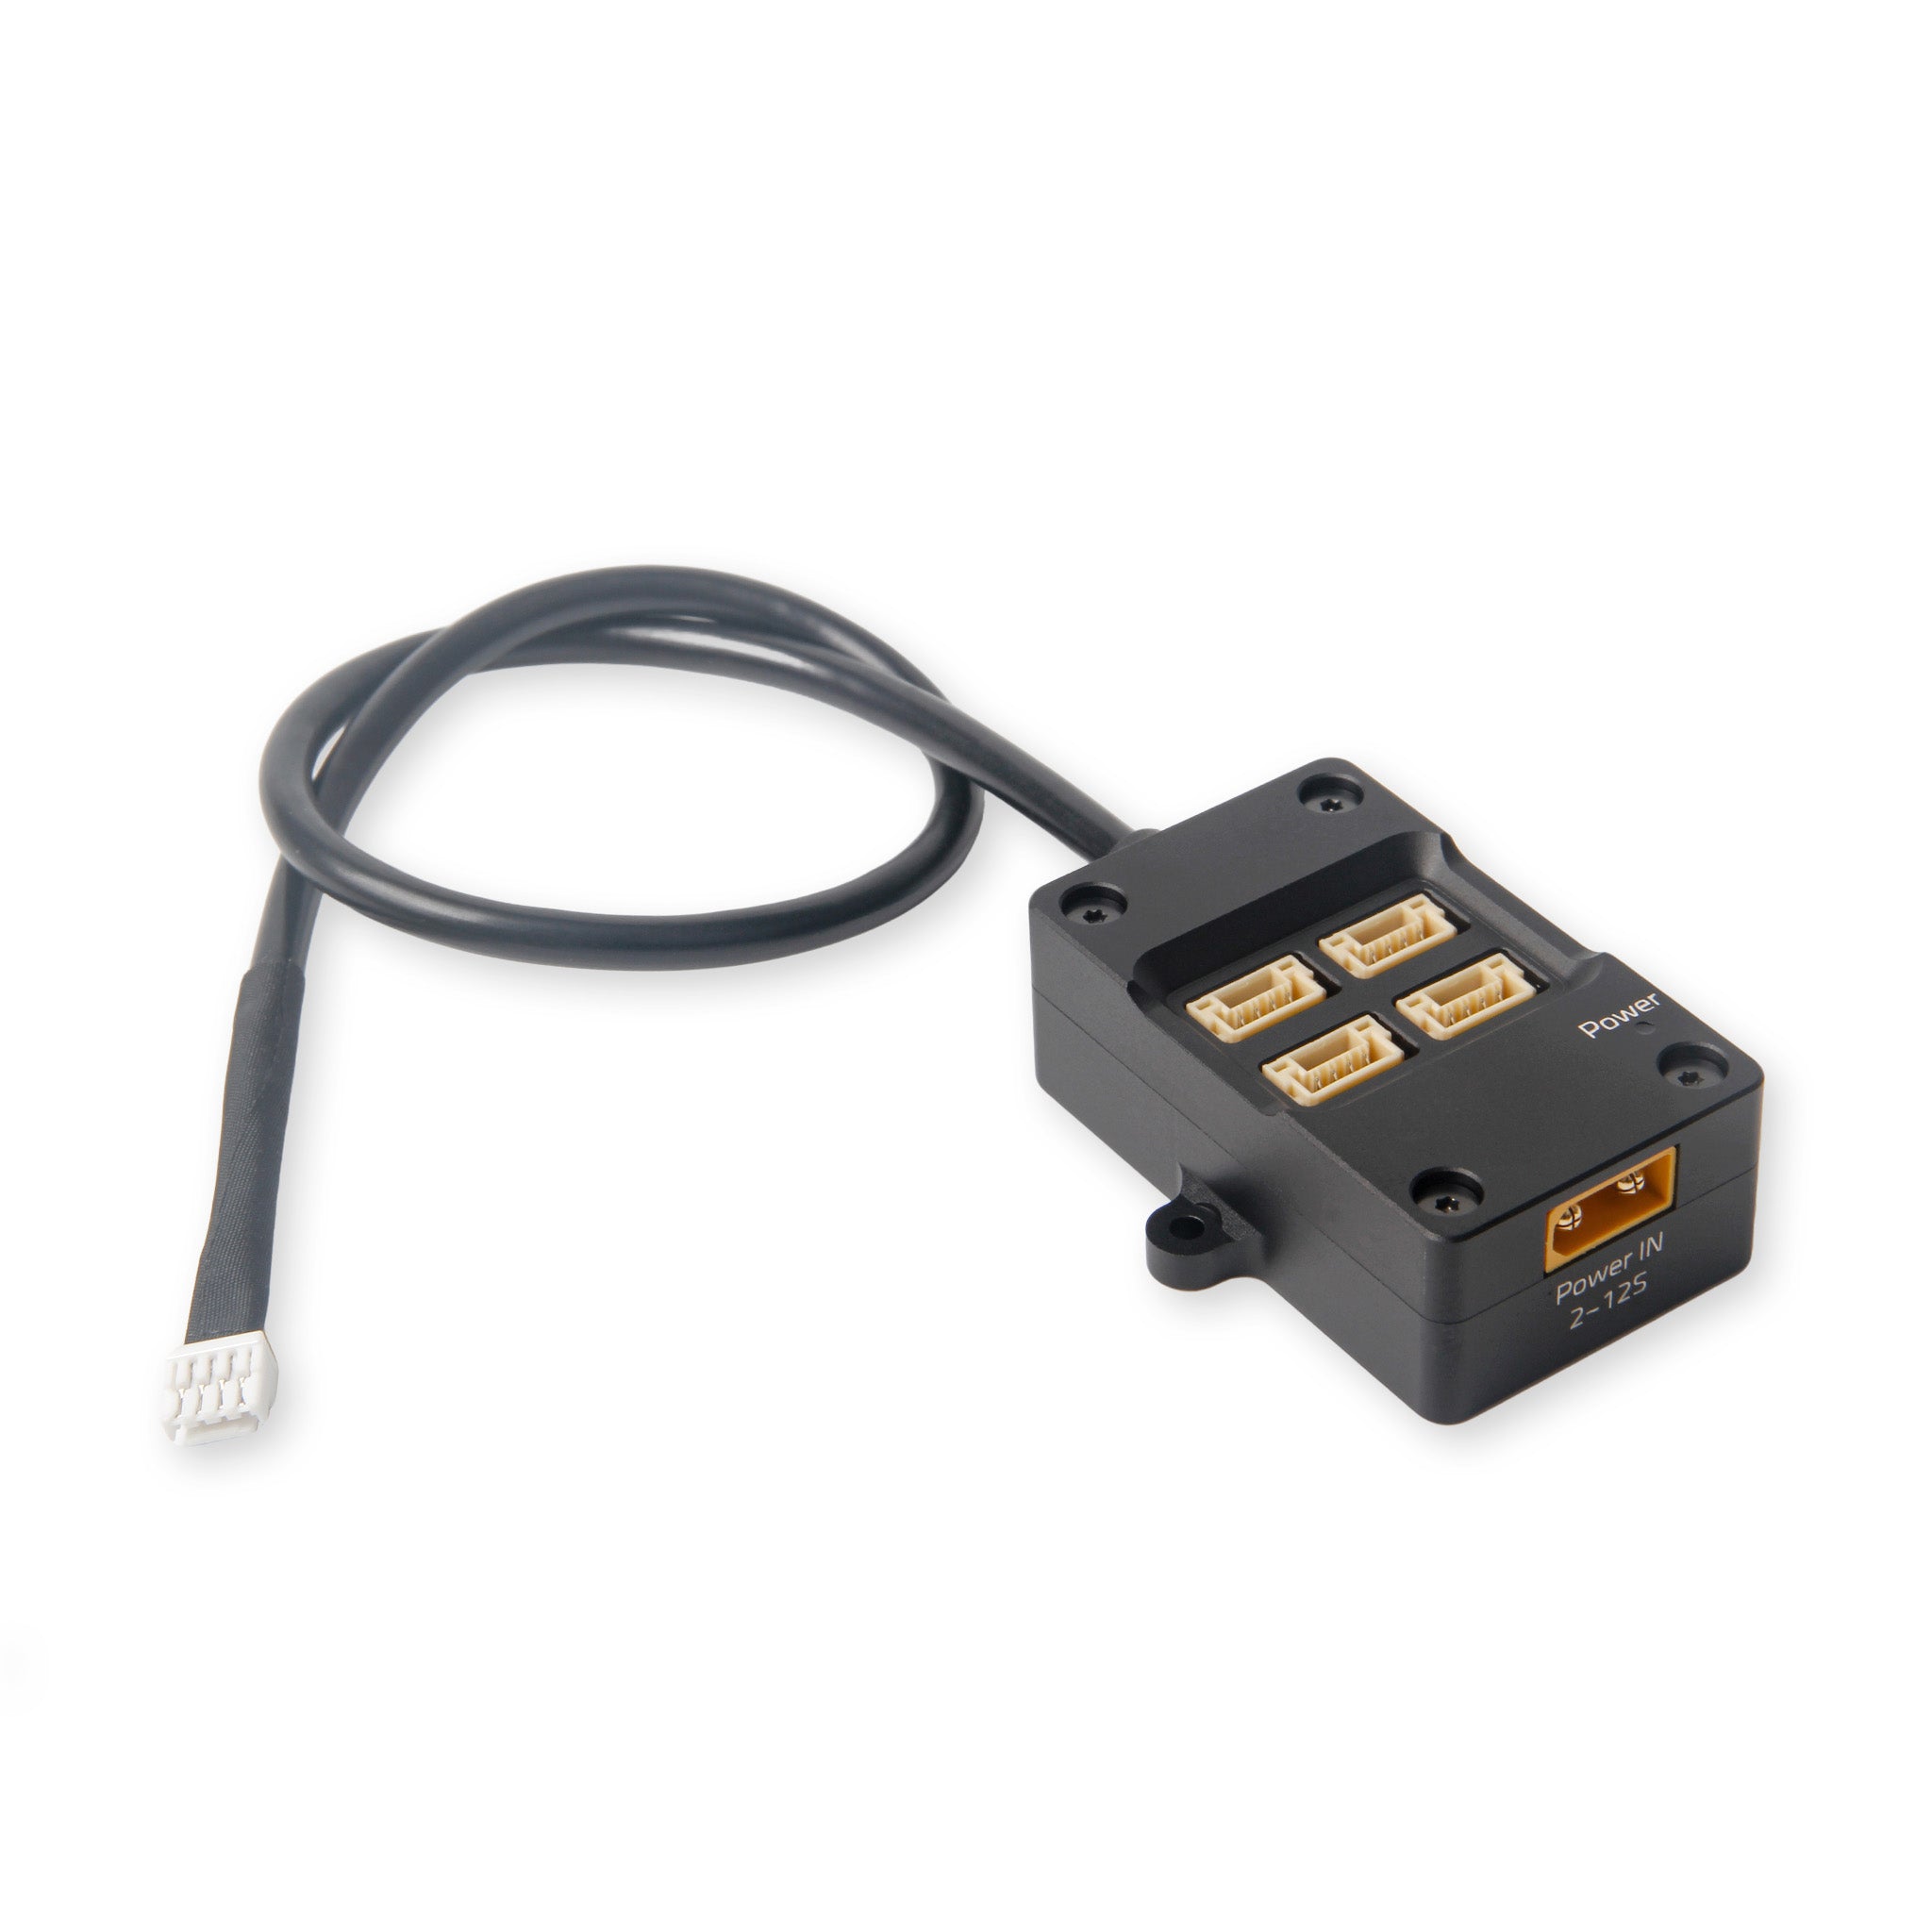
Holybro CAN Hub — yellow XT30 “Power IN 2–12S” is required for stable F9P + H-Flow
Naming: “lidar + GPS on CAN” = H-Flow ToF + F9P. The LD-06 is on TELEM1 (UART), not CAN. We still mix that up sometimes — hence the tip.
That keeps prop spikes off the sensitive FC rail. Details: step 2 — FC & power.
Capacitor: on the ESC, not the PM
The Pacer kit includes one capacitor. We solder that on the ESC power pads (near XT60), polarity correct. The PM02D already has an on-board capacitor — no need to stick a second one on “for show”.
For 8″ / 6S the included cap is a start. Oscar Liang roughly recommends ~2200 µF or 2× 1000 µF parallel, voltage 35 V or better 50 V. Read: Why capacitors matter.
On ArduPilot this is mostly cleaner power and spike protection. Reliability first. FPV video noise is a side effect here.
What we do on the bench
- Split XT60 from the pack via Y/adapters to Pacer, PM02D, O4, and CAN Hub XT30.
- Confirm CAN Hub Power LED; F9P + H-Flow online without FC 5V brownout.
- Mount the cap on the ESC (or upgrade).
- First boot without props: FC starts, LED/buzzer OK.
- Then sensors and radio — step 3 and step 4.
Read next
ArduPilot: Powering the Pixhawk · Power module · ESCs / motor power
Choice log
| What | Pack rail in parallel: ESC + PM02D + O4 + CAN Hub XT30; low-ESR cap on ESC |
| Why | Keep prop spikes off the FC; enough 5 V for F9P + H-Flow |
| Our pick | Y from the pack — not everything via ESC BEC or thin CAN 5V alone |
Photos